Initializing Systems
About Experience Skills Projects Research Contact
// Robotics & AI Engineer

Umer Ahmed Baig
Mughal

Research-focused Robotics & AI Engineer with a passion for building intelligent machines that perceive, decide, and act. Specialized in autonomous systems, deep learning-driven perception, and adaptive control — turning complex algorithms into robust real-world solutions at the intersection of hardware and software.

Machine Learning Computer Vision Deep Learning Embedded Systems Robotic Motion Control Autonomous Systems Human-Robot Interaction
0GitHub Repos
0Publication
0Industry Years
0Hackathon Awards
Scroll
01

About

umer@itmo:~/ — profile.py
# ─── Researcher | Engineer | Builder ───────────
class UmerAhmedBaigMughal:
role = "MSc Robotics & AI Engineer"
university = "ITMO University, Saint Petersburg"
focus = ["Autonomous Systems", "Computer Vision", "Intelligent Control"]
industry_exp = "3+ years (R&D & Lab Management)"
publication = "IJGDC Vol.13 No.2 (2020)"
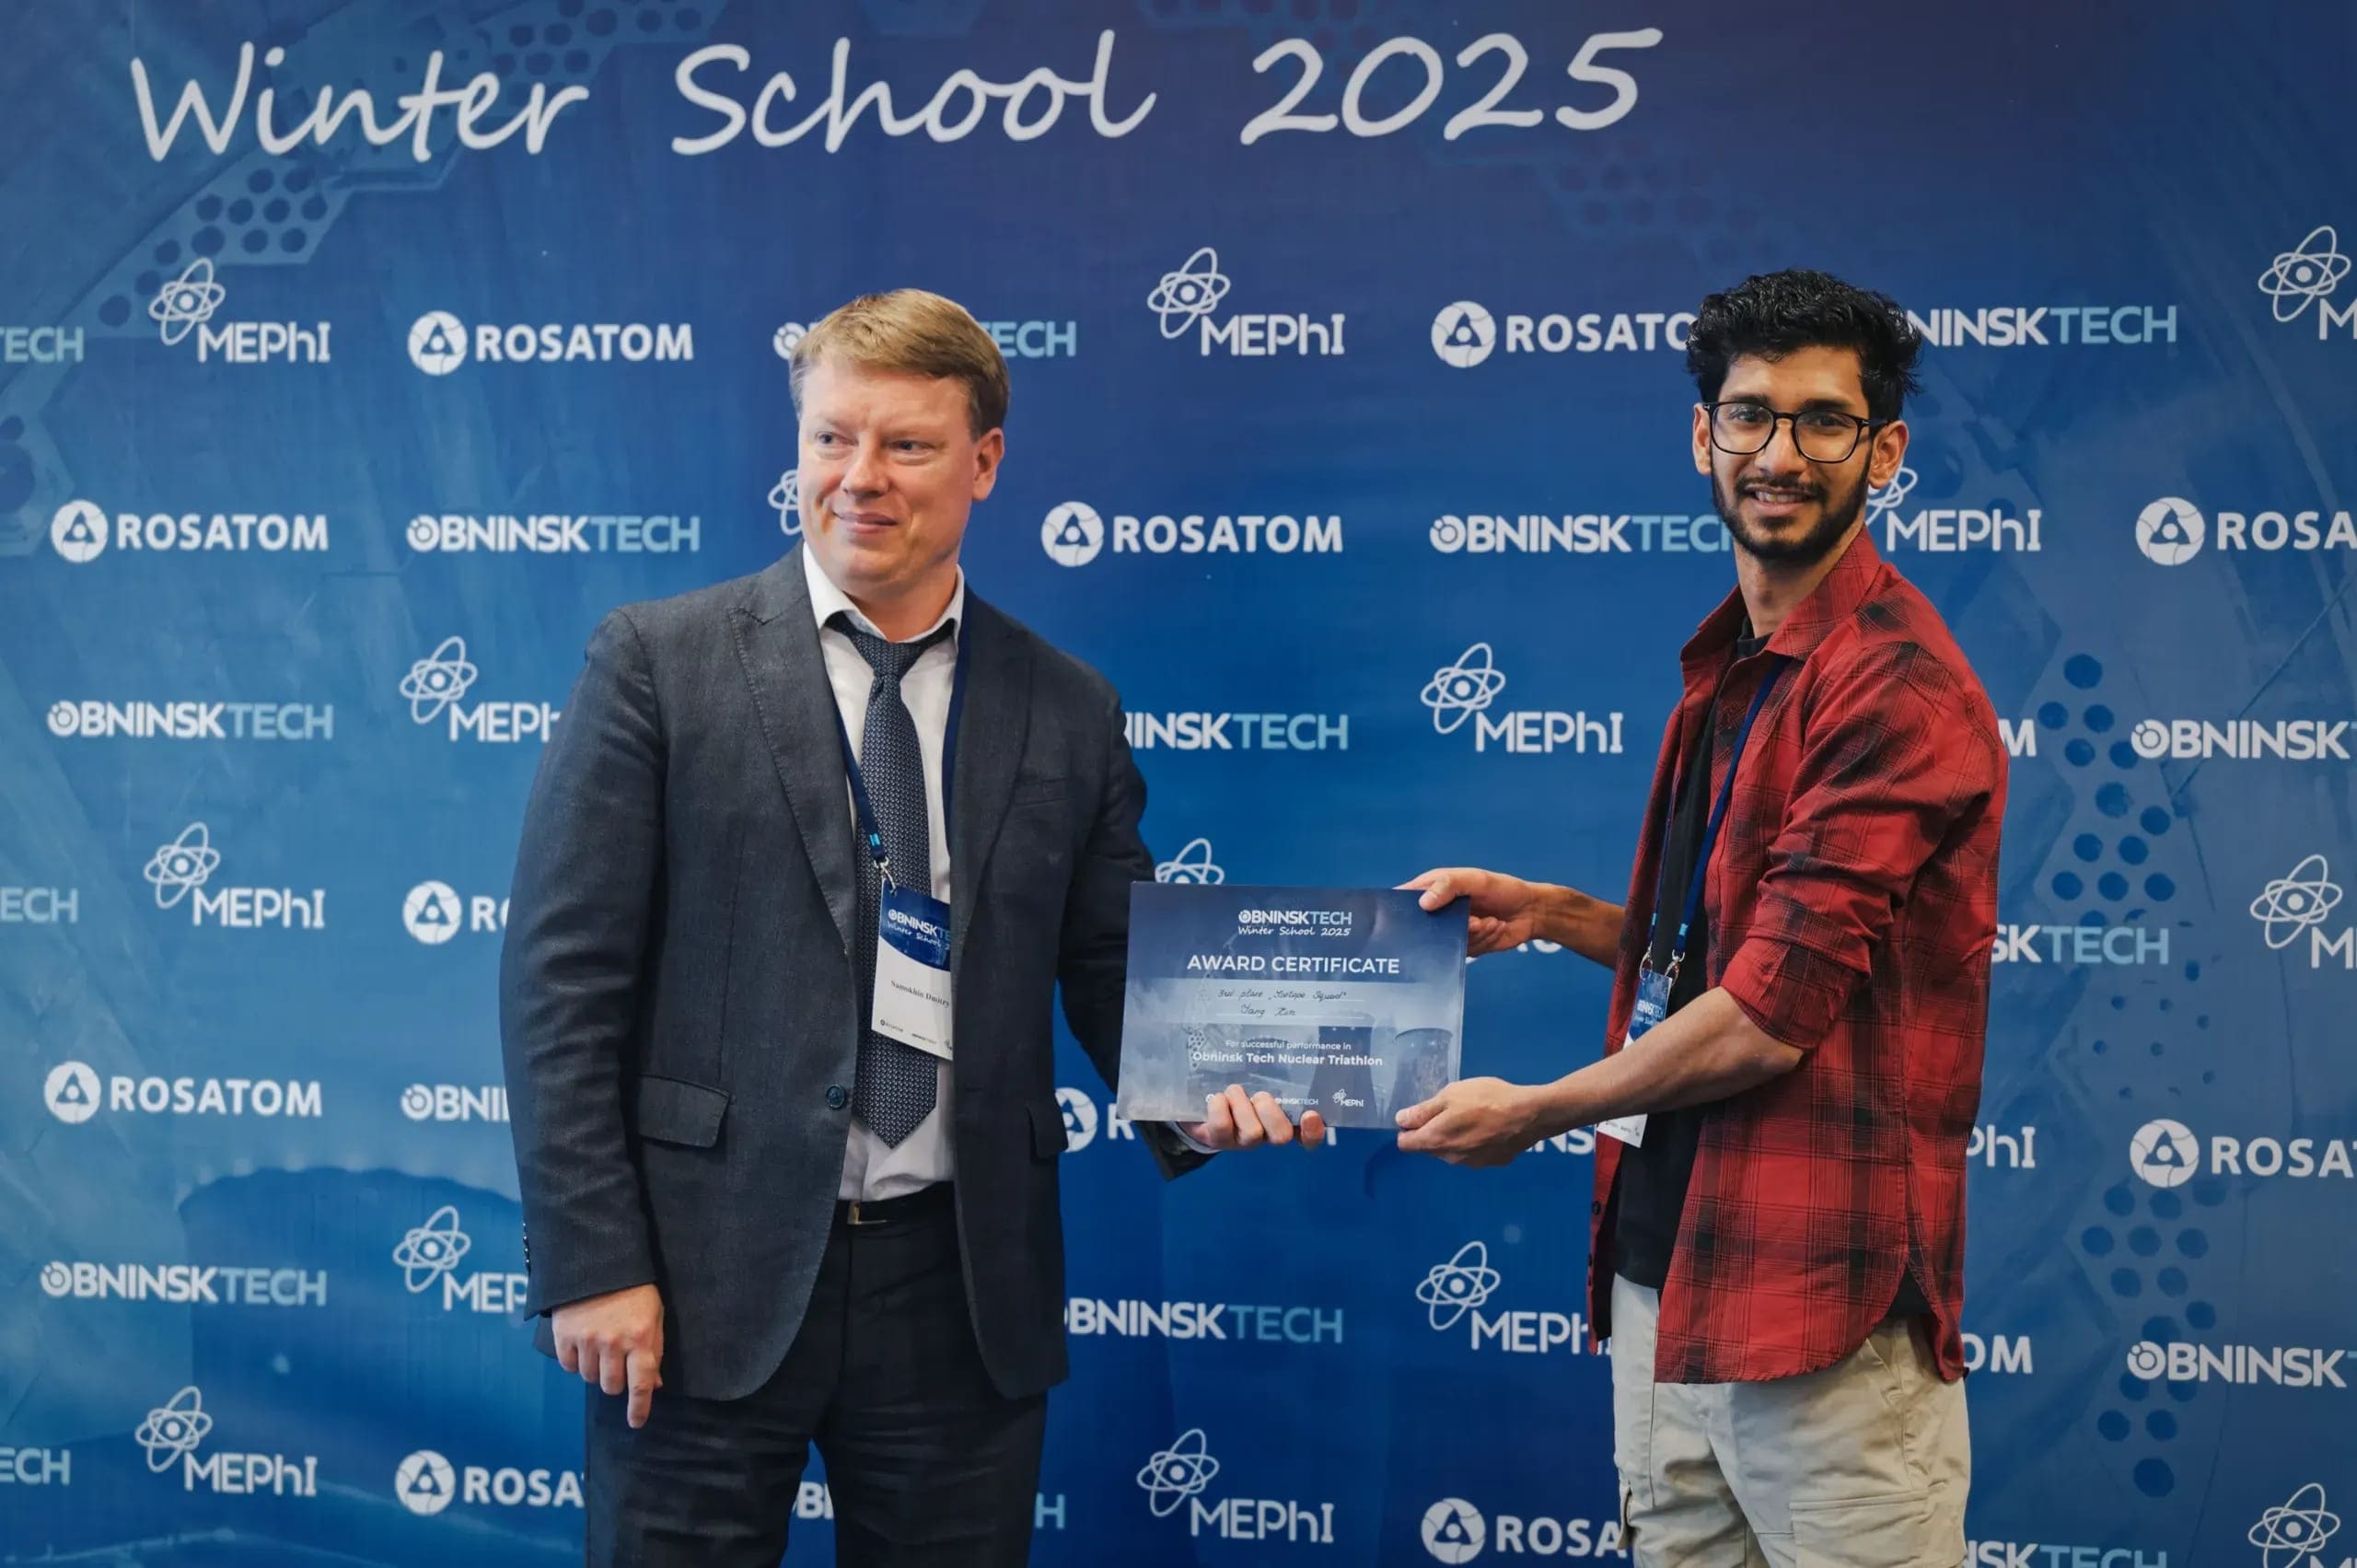
awards = ["1st Eng Hackathon", "1st Atomic Triathlon", "3rd Winter Hackathon"]
languages = ["Urdu (Native)", "English (Fluent)", "Russian (Learning)"]
 
"""
I build intelligent robotic systems — from perception algorithms
and control frameworks to deep learning pipelines for real-world
autonomous decision-making. My current research focuses on
AI-driven perception & adaptive control for smart infrastructure.
"""
 
print("Open to PhD roles, research collaborations & robotics engineering")
Umer Ahmed Baig Mughal
Umer Ahmed Baig
Email
Phone +92 348 366 1218
LinkedIn umer-ahmed-baig7
GitHub umerahmedbaig7
Origin Karachi, Pakistan
Status ● Open to opportunities
02

Experience & Education

My Lighting (Private) Limited
Lab Manager
09/2022 – 10/2024
Karachi, Pakistan
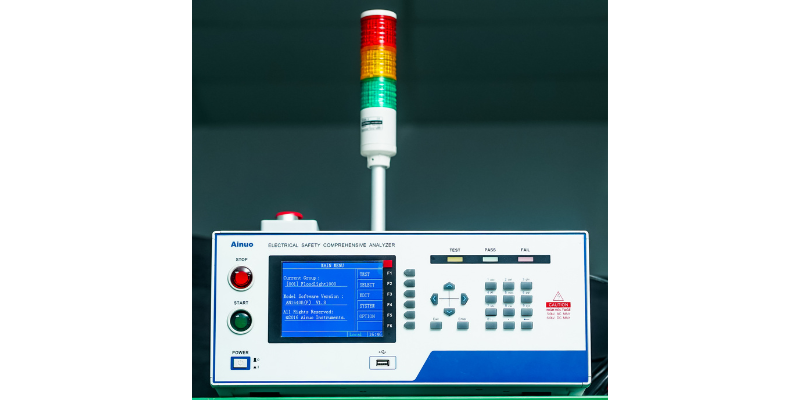
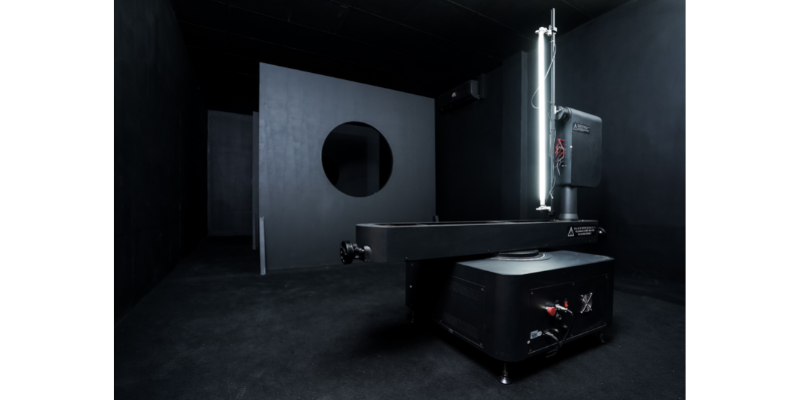
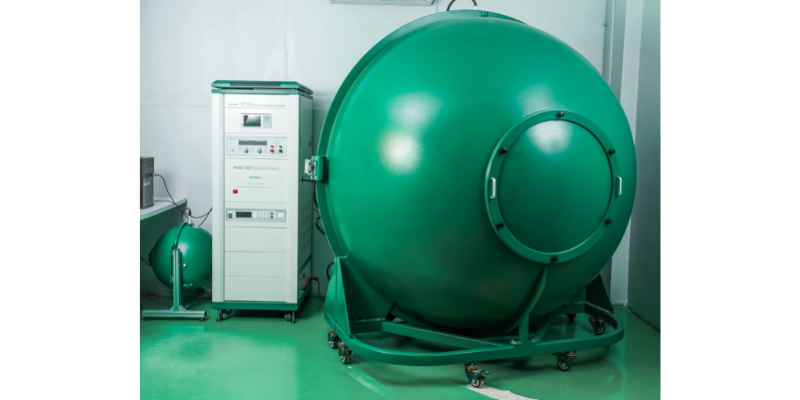
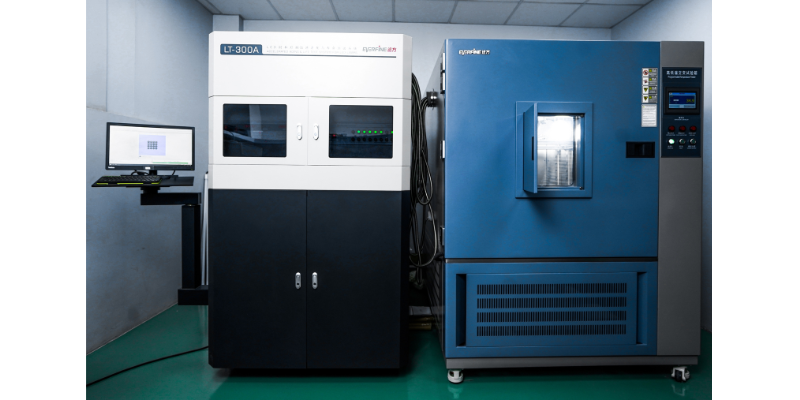
  • Developed and managed quality control and R&D protocols for indoor and outdoor lighting products, including photometric and goniophotometric measurements.
  • Generated IES design files, photometric reports, and validation data to ensure compliance with international lighting standards.
  • Led the R&D team in evaluating product samples, reviewing assembly and quality SOPs, and supervising junior staff.
  • Optimized workflow integration between hardware testing, software simulation, and data analysis pipelines.
Pakistan Lighting LED Private Limited
Lab Engineer
02/2021 – 08/2022
Karachi, Pakistan
  • Developed and managed laboratory protocols for luminaire testing and IES file generation using DIALux.
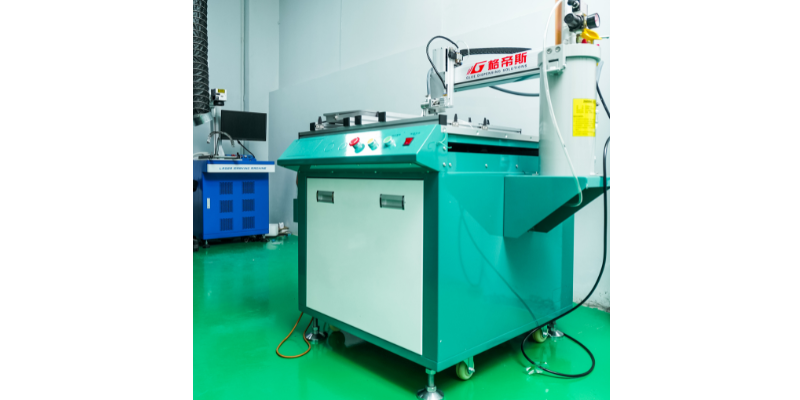
  • Operated and calibrated precision instrumentation: spectroradiometers, SMT PCB assembly systems, laser-marking equipment, and LED driver test benches.
  • Optimized experimental workflows by integrating DIALux simulations with hardware testing, correlating electrical performance with photometric outcomes.
  • Organized and delivered training sessions on laboratory instrumentation and experimental procedures.
// Education
09/2024 – 08/2026
MSc Robotics & Artificial Intelligence
ITMO University
Saint Petersburg, Russia · CGPA: 4.9/5.0
01/2016 – 12/2019
BEng Electronic Engineering
Mehran University of Engineering & Technology
Jamshoro, Pakistan · CGPA: 3.01/4.0
08/2013 – 08/2015
Intermediate (Pre-Engineering)
College of Excellence for Boys
Hyderabad, Pakistan · 74.5%
04/2011 – 04/2013
Matriculation
Public School Hyderabad
Hyderabad, Pakistan · 76.2%
03

Skills & Expertise

Core Proficiency
Python92%
PyTorch / TensorFlow87%
OpenCV / Computer Vision85%
ROS / Robotics Middleware82%
C / C++82%
MATLAB / Simulink84%
MuJoCo / Gazebo Simulation83%
LabVIEW80%
NI Multisim80%
AI & Machine Learning
Deep LearningNeRF / 3D Reconstruction CNNs / SegNetAutoencoders Reinforcement LearningTransfer Learning Jupyter / Colab
Robotics & Control
PID ControlMPC DWA NavigationA* Path Planning EKF / UKFTrajectory Planning SLAMRobotic Motion Control
Embedded & Hardware
ArduinoSTM32 PCB DesignAutoCAD SMT AssemblyIoT Systems LiDAR Sensing
Tools & Professional
Git / GitHubDIALux Technical WritingProject Management Team LeadershipR&D Protocols
04

Projects

Featured
09/2025 – 02/2026
Depth-Supervised Neural Radiance Fields for Geometrically Consistent 3D Reconstruction
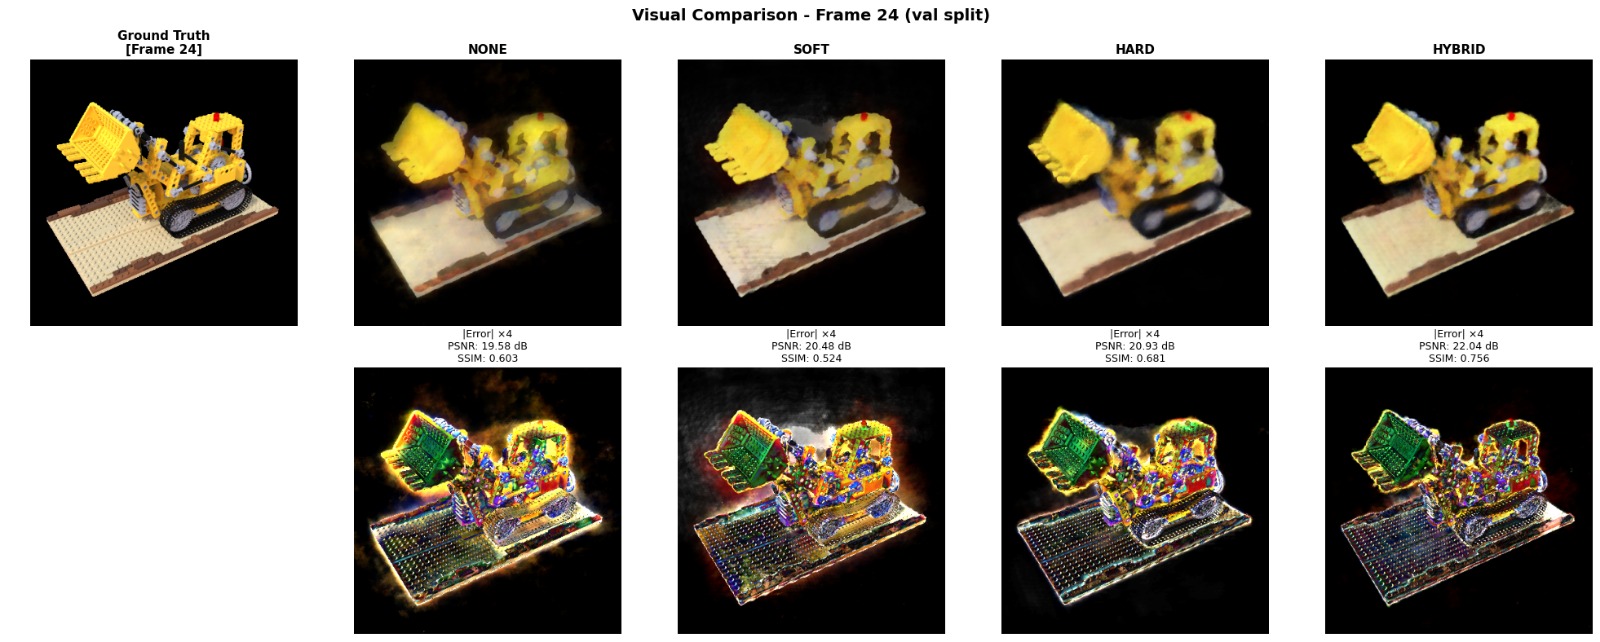
Systematic study enhancing NeRF training using structured depth supervision. Implemented four strategies — RGB-only, soft depth, hard geometric constraints, and hybrid. Achieved highest validation PSNR of 22.32 dB using hybrid strategy, outperforming RGB-only baseline by +2.4 dB.
NeRF3D ReconstructionPython PSNR / SSIMDepth Supervision
02/2025 – 06/2025
TriNav: A Tri-Layer Navigation Framework for Autonomous Mobile Robots
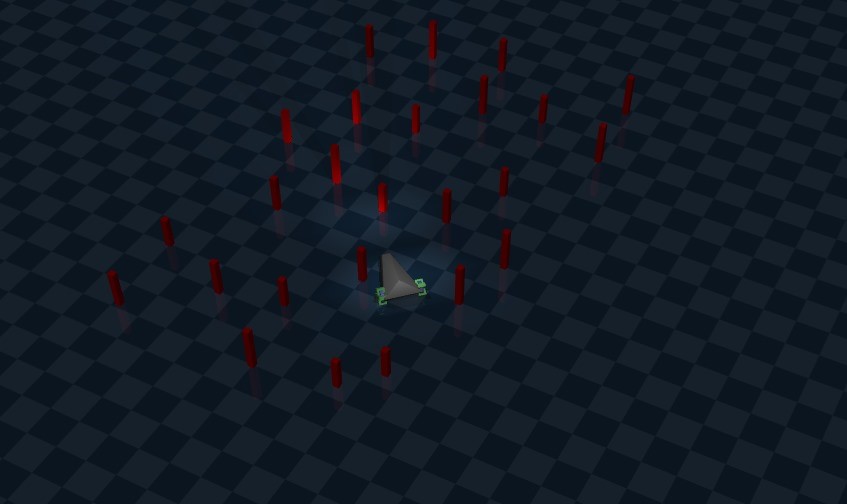
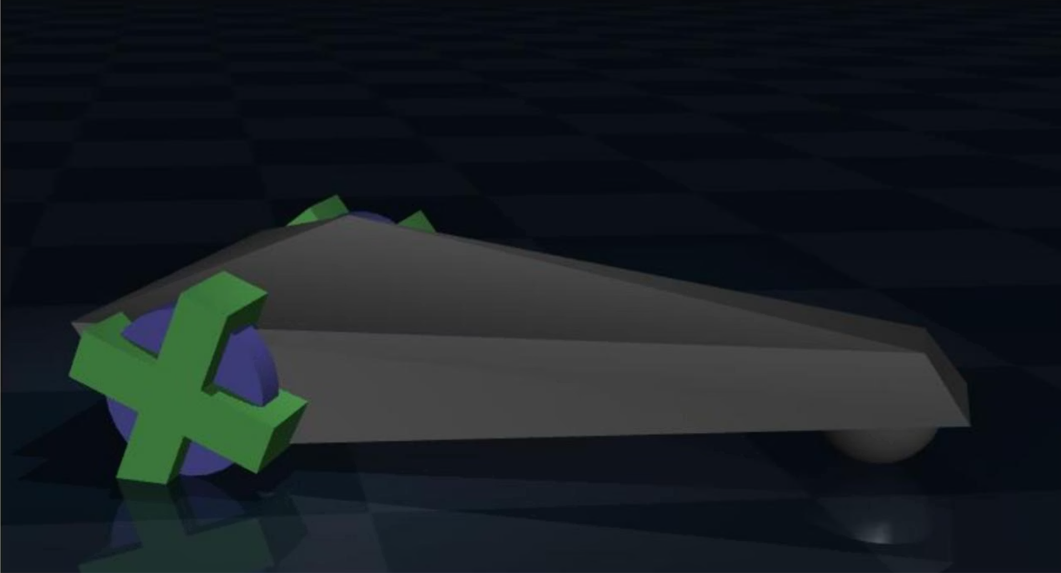
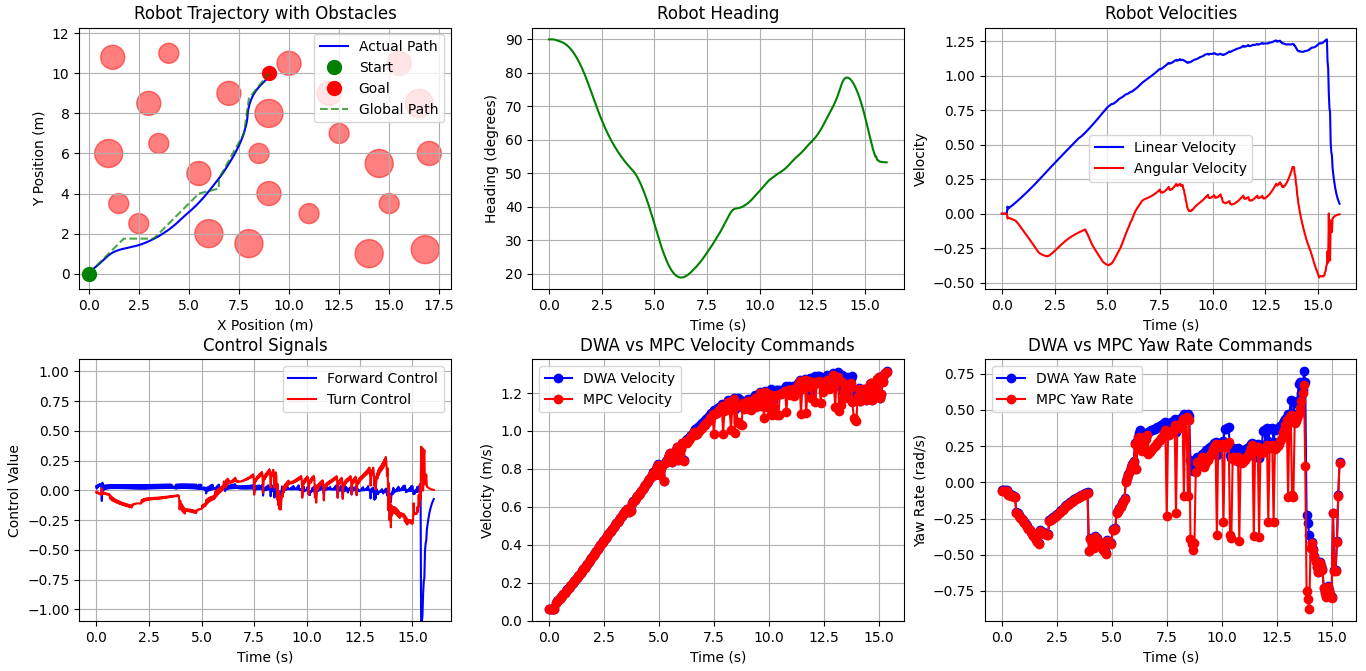
Hybrid navigation framework combining global (A*), local (DWA), and optimal control (MPC) layers. Simulated differential-drive robot motion in MuJoCo — achieving obstacle avoidance, trajectory tracking, and goal convergence with real-time performance.
MuJoCoA* / DWAMPC PIDROSPython
10/2018 – 10/2019
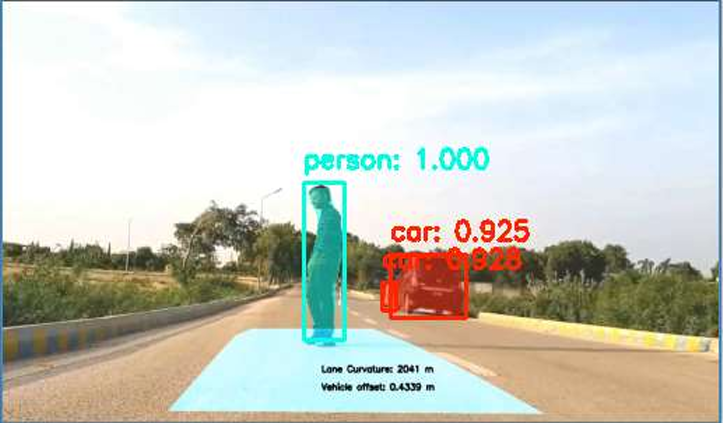
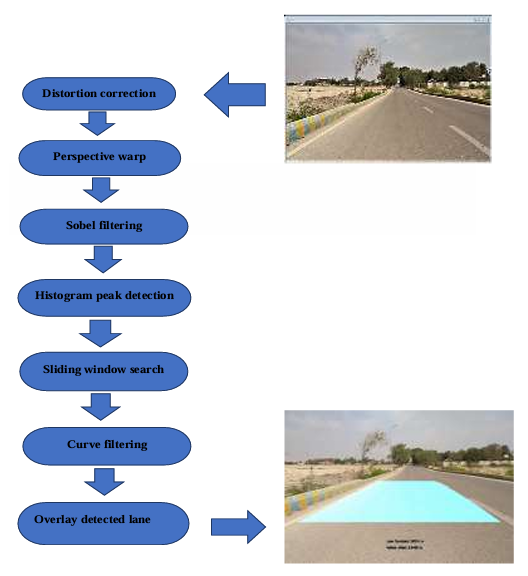
Self-Driving Car Using LiDAR Sensing and Image Processing
Framework using CNN / Mask R-CNN for enhanced environment perception and obstacle detection in autonomous vehicles. Validated through simulation and real-world testing. Published in International Journal of GDC (Vol. 13, No. 2, pp. 77–88).
CNNMask R-CNNLiDAR Computer VisionPublished
MSc Coursework
Machine Learning in Robotics — End-to-End Pipeline Collection
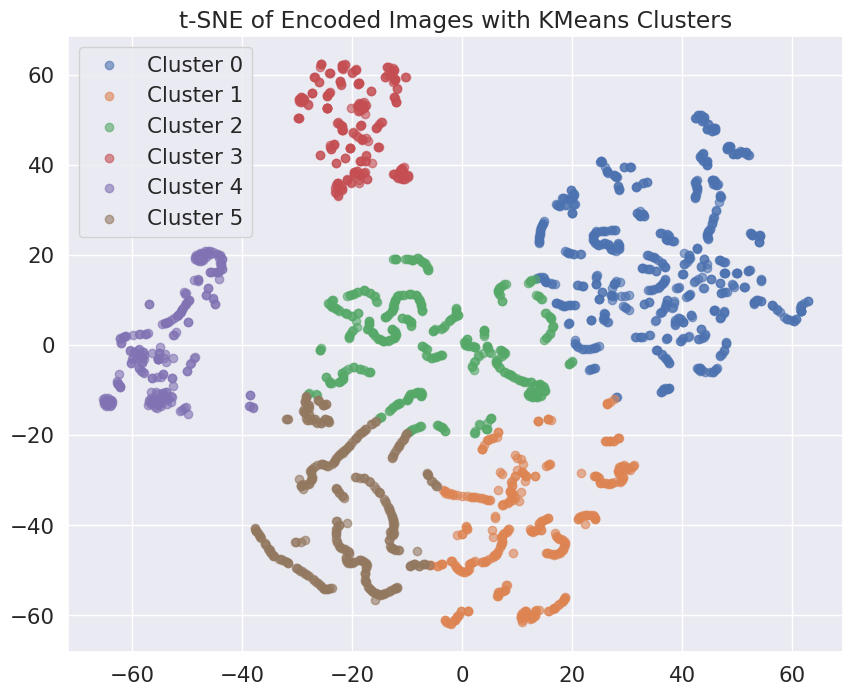
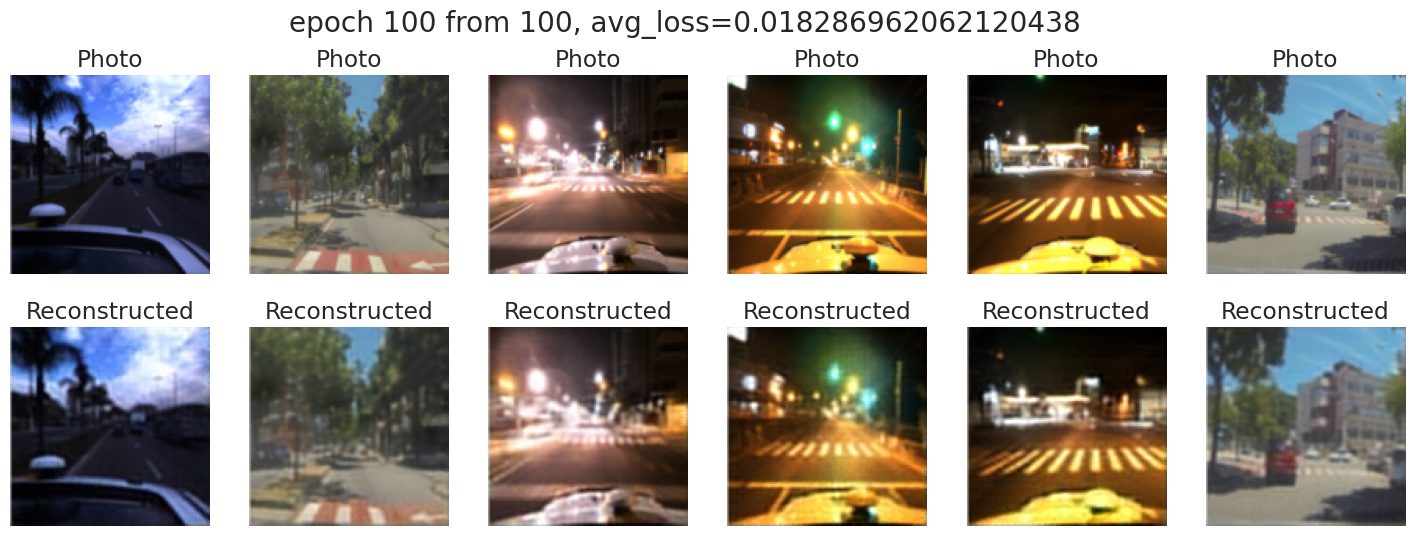
Covers supervised image classification, binary segmentation with SegNet, unsupervised convolutional autoencoders with latent-space clustering, and reinforcement learning for robotic tasks. Implemented end-to-end pipelines in PyTorch with full evaluation metrics.
SegNetAutoencodersPyTorch RLJupyterITMO
View All on GitHub →
05

Publications & Research
GYRO NAV
2026
TriLayer-Nav: A Tri-Layer Navigation Framework Integrating A*, Dynamic Window Approach, and Model Predictive Control for Differential-Drive Robots
Gyroscopy and Navigation · Springer · Vol. 17, pp. 24–33 · Issue: March 2026
Mughal, U.A., Ali, A., Urwa, et al. "TriLayer-Nav: A Tri-Layer Navigation Framework Integrating A*, Dynamic Window Approach, and Model Predictive Control for Differential-Drive Robots." Gyroscopy and Navigation, vol. 17, pp. 24–33, 2026.
View Journal
IJGDC
2020
Self-Driving Car Using LiDAR Sensing and Image Processing
International Journal of Grid and Distributed Computing (IJGDC) · NADIA · ISSN: 2005-4262 · Vol. 13 No. 2
Umer Ahmed Baig, et al. "Self-Driving Car using Lidar Sensing and Image Processing." IJGDC, vol. 13, no. 2, pp. 77–88, 2020.
View Journal
// Awards & Achievements
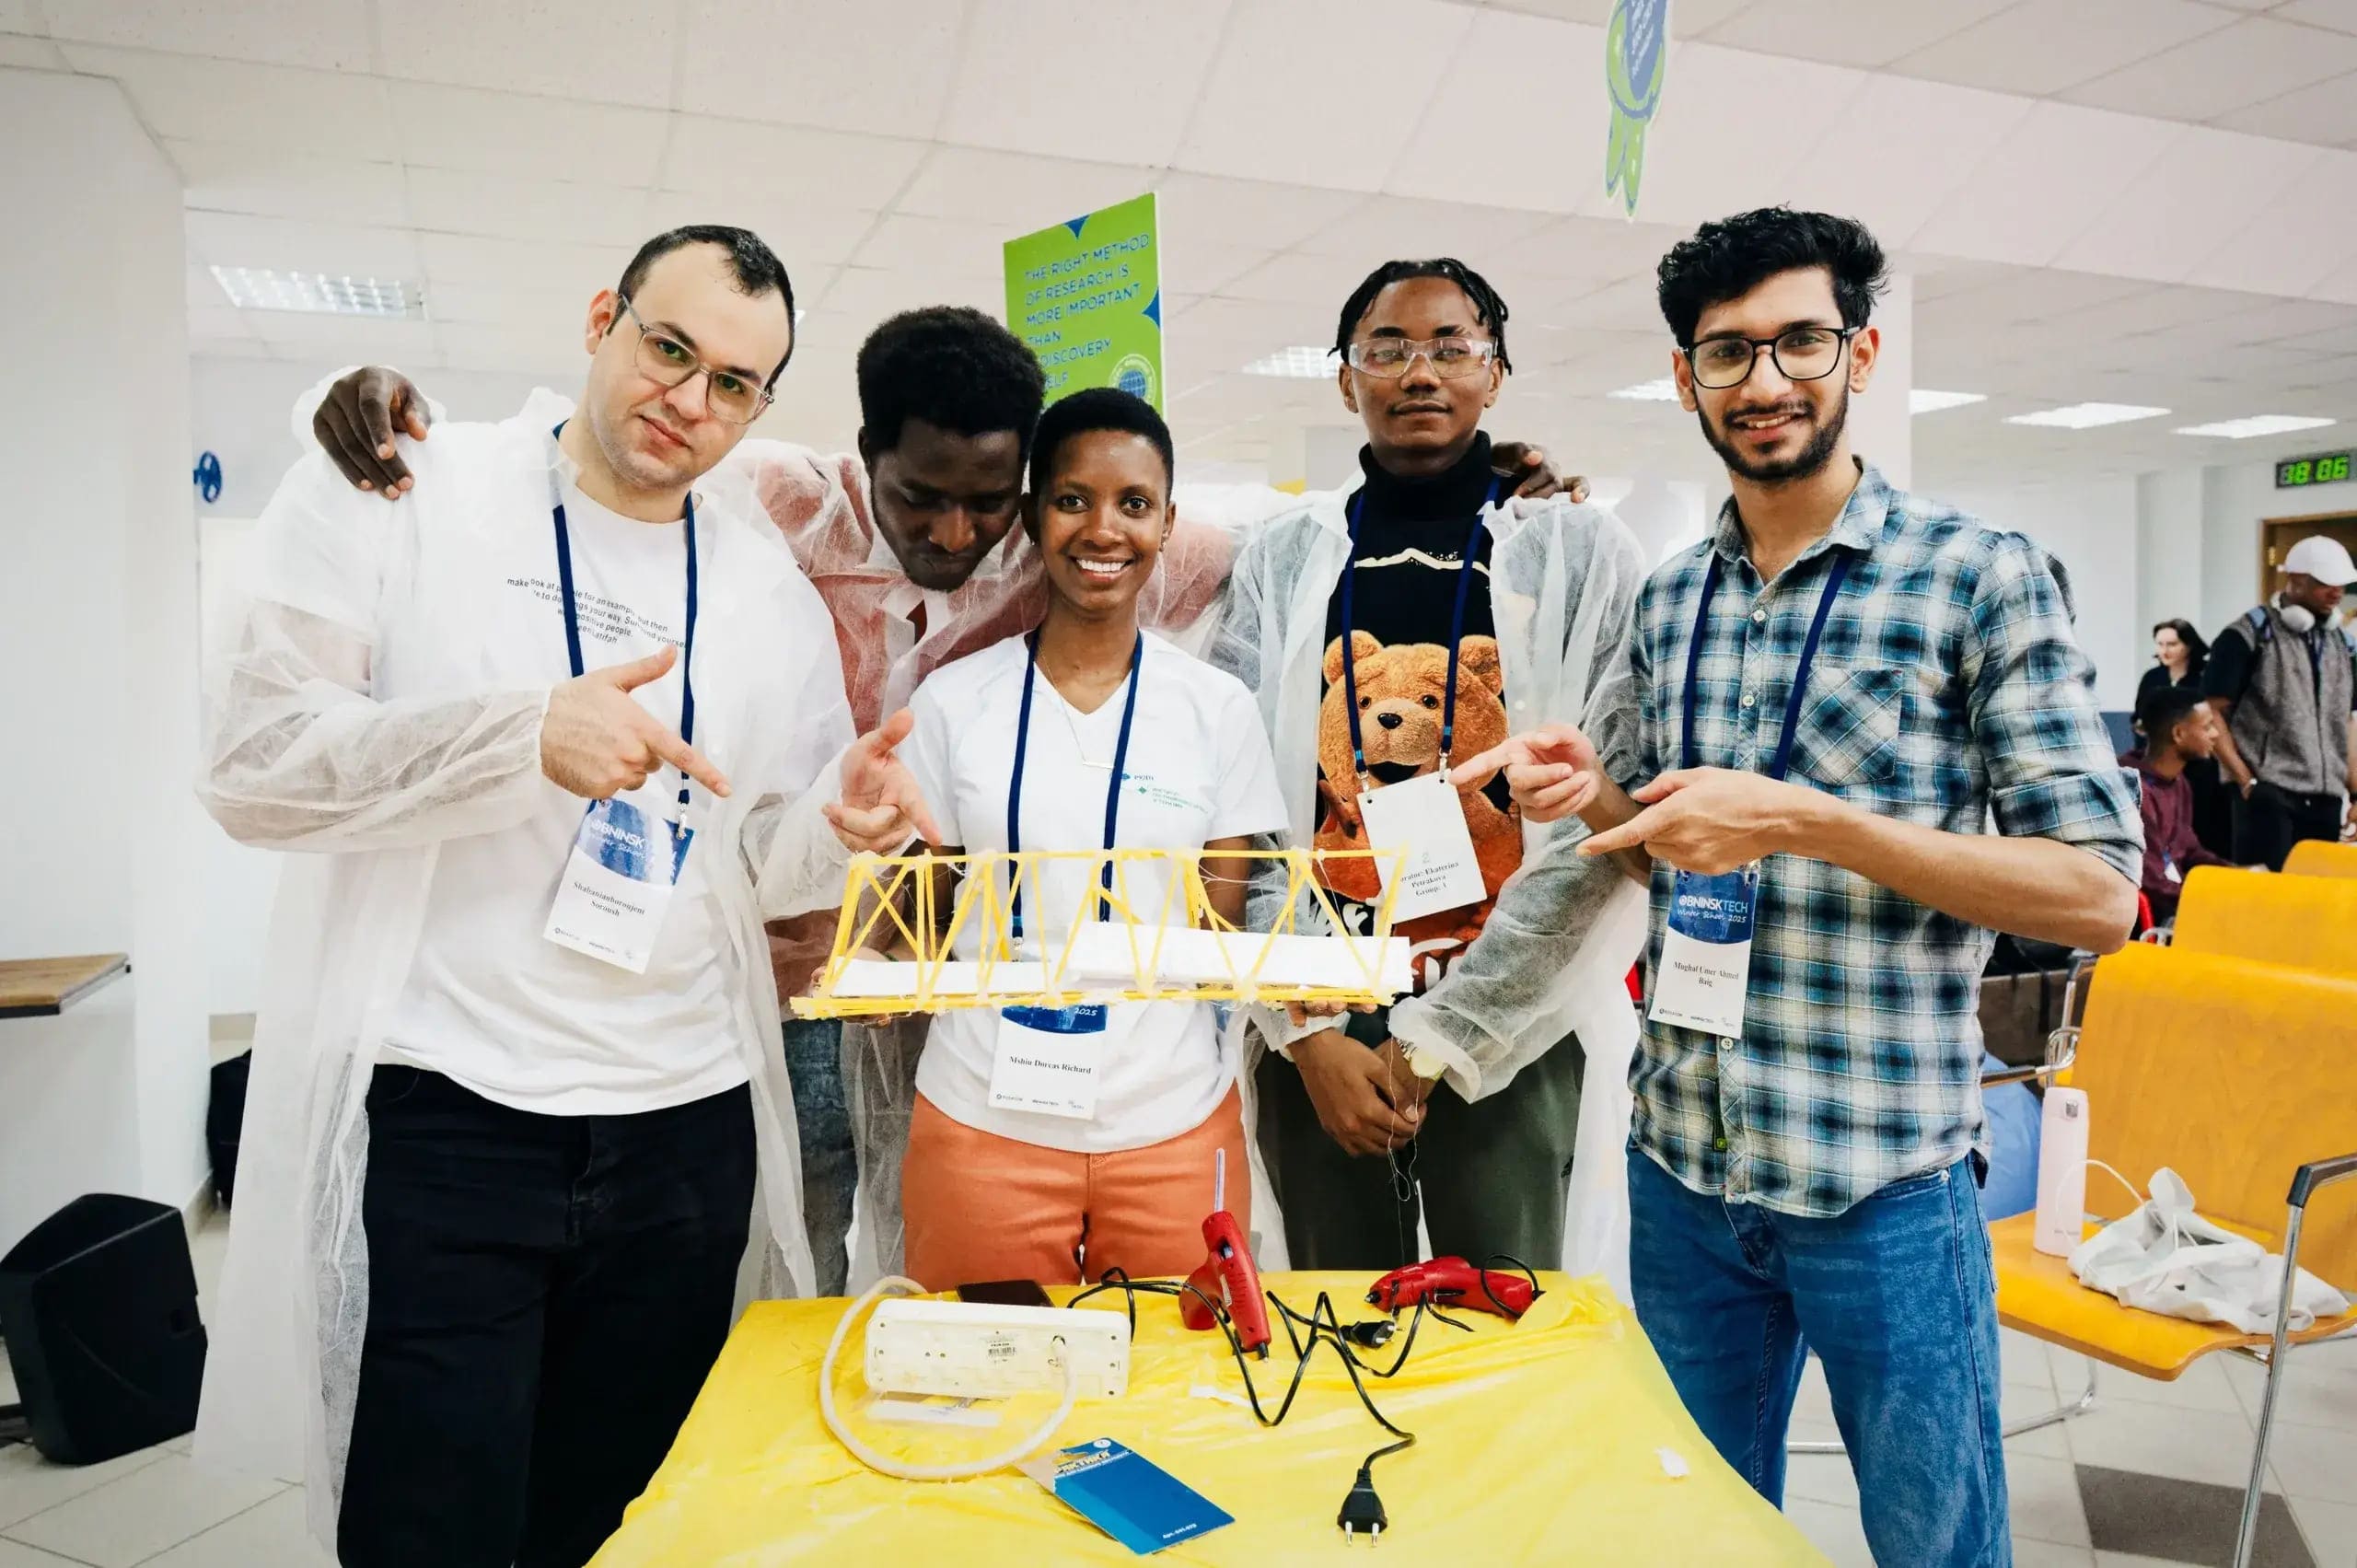
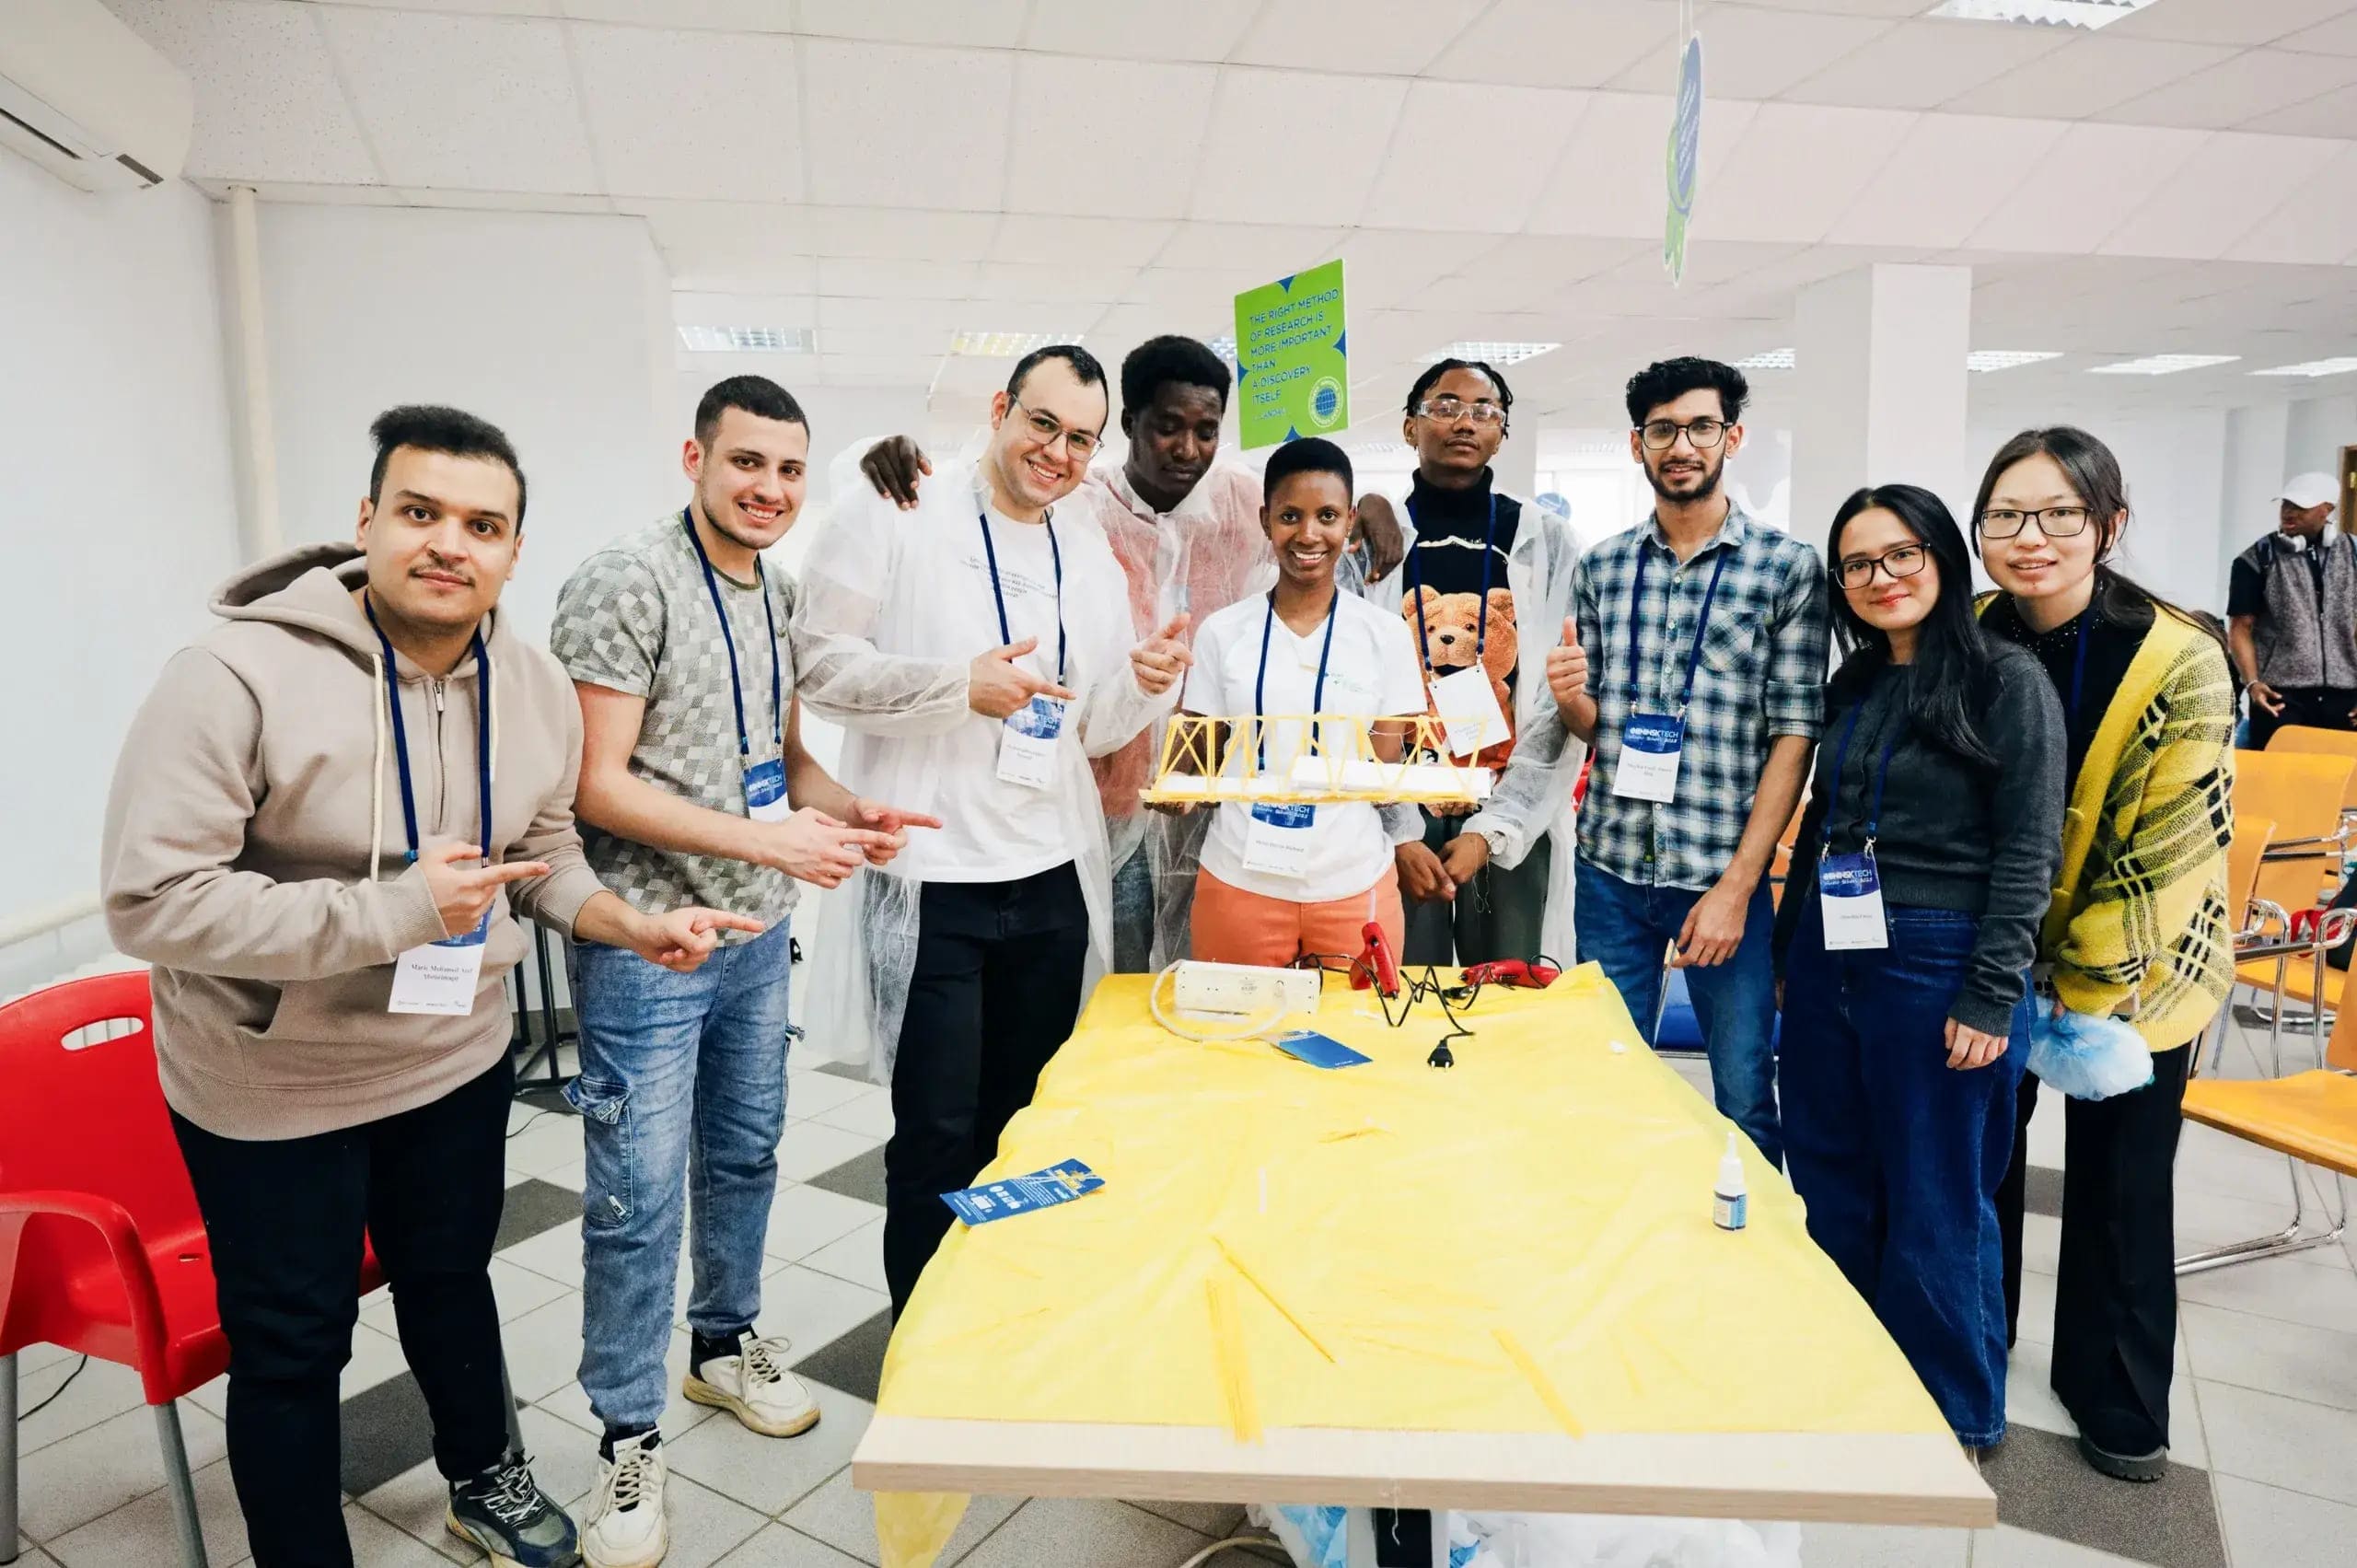
28 June 2025
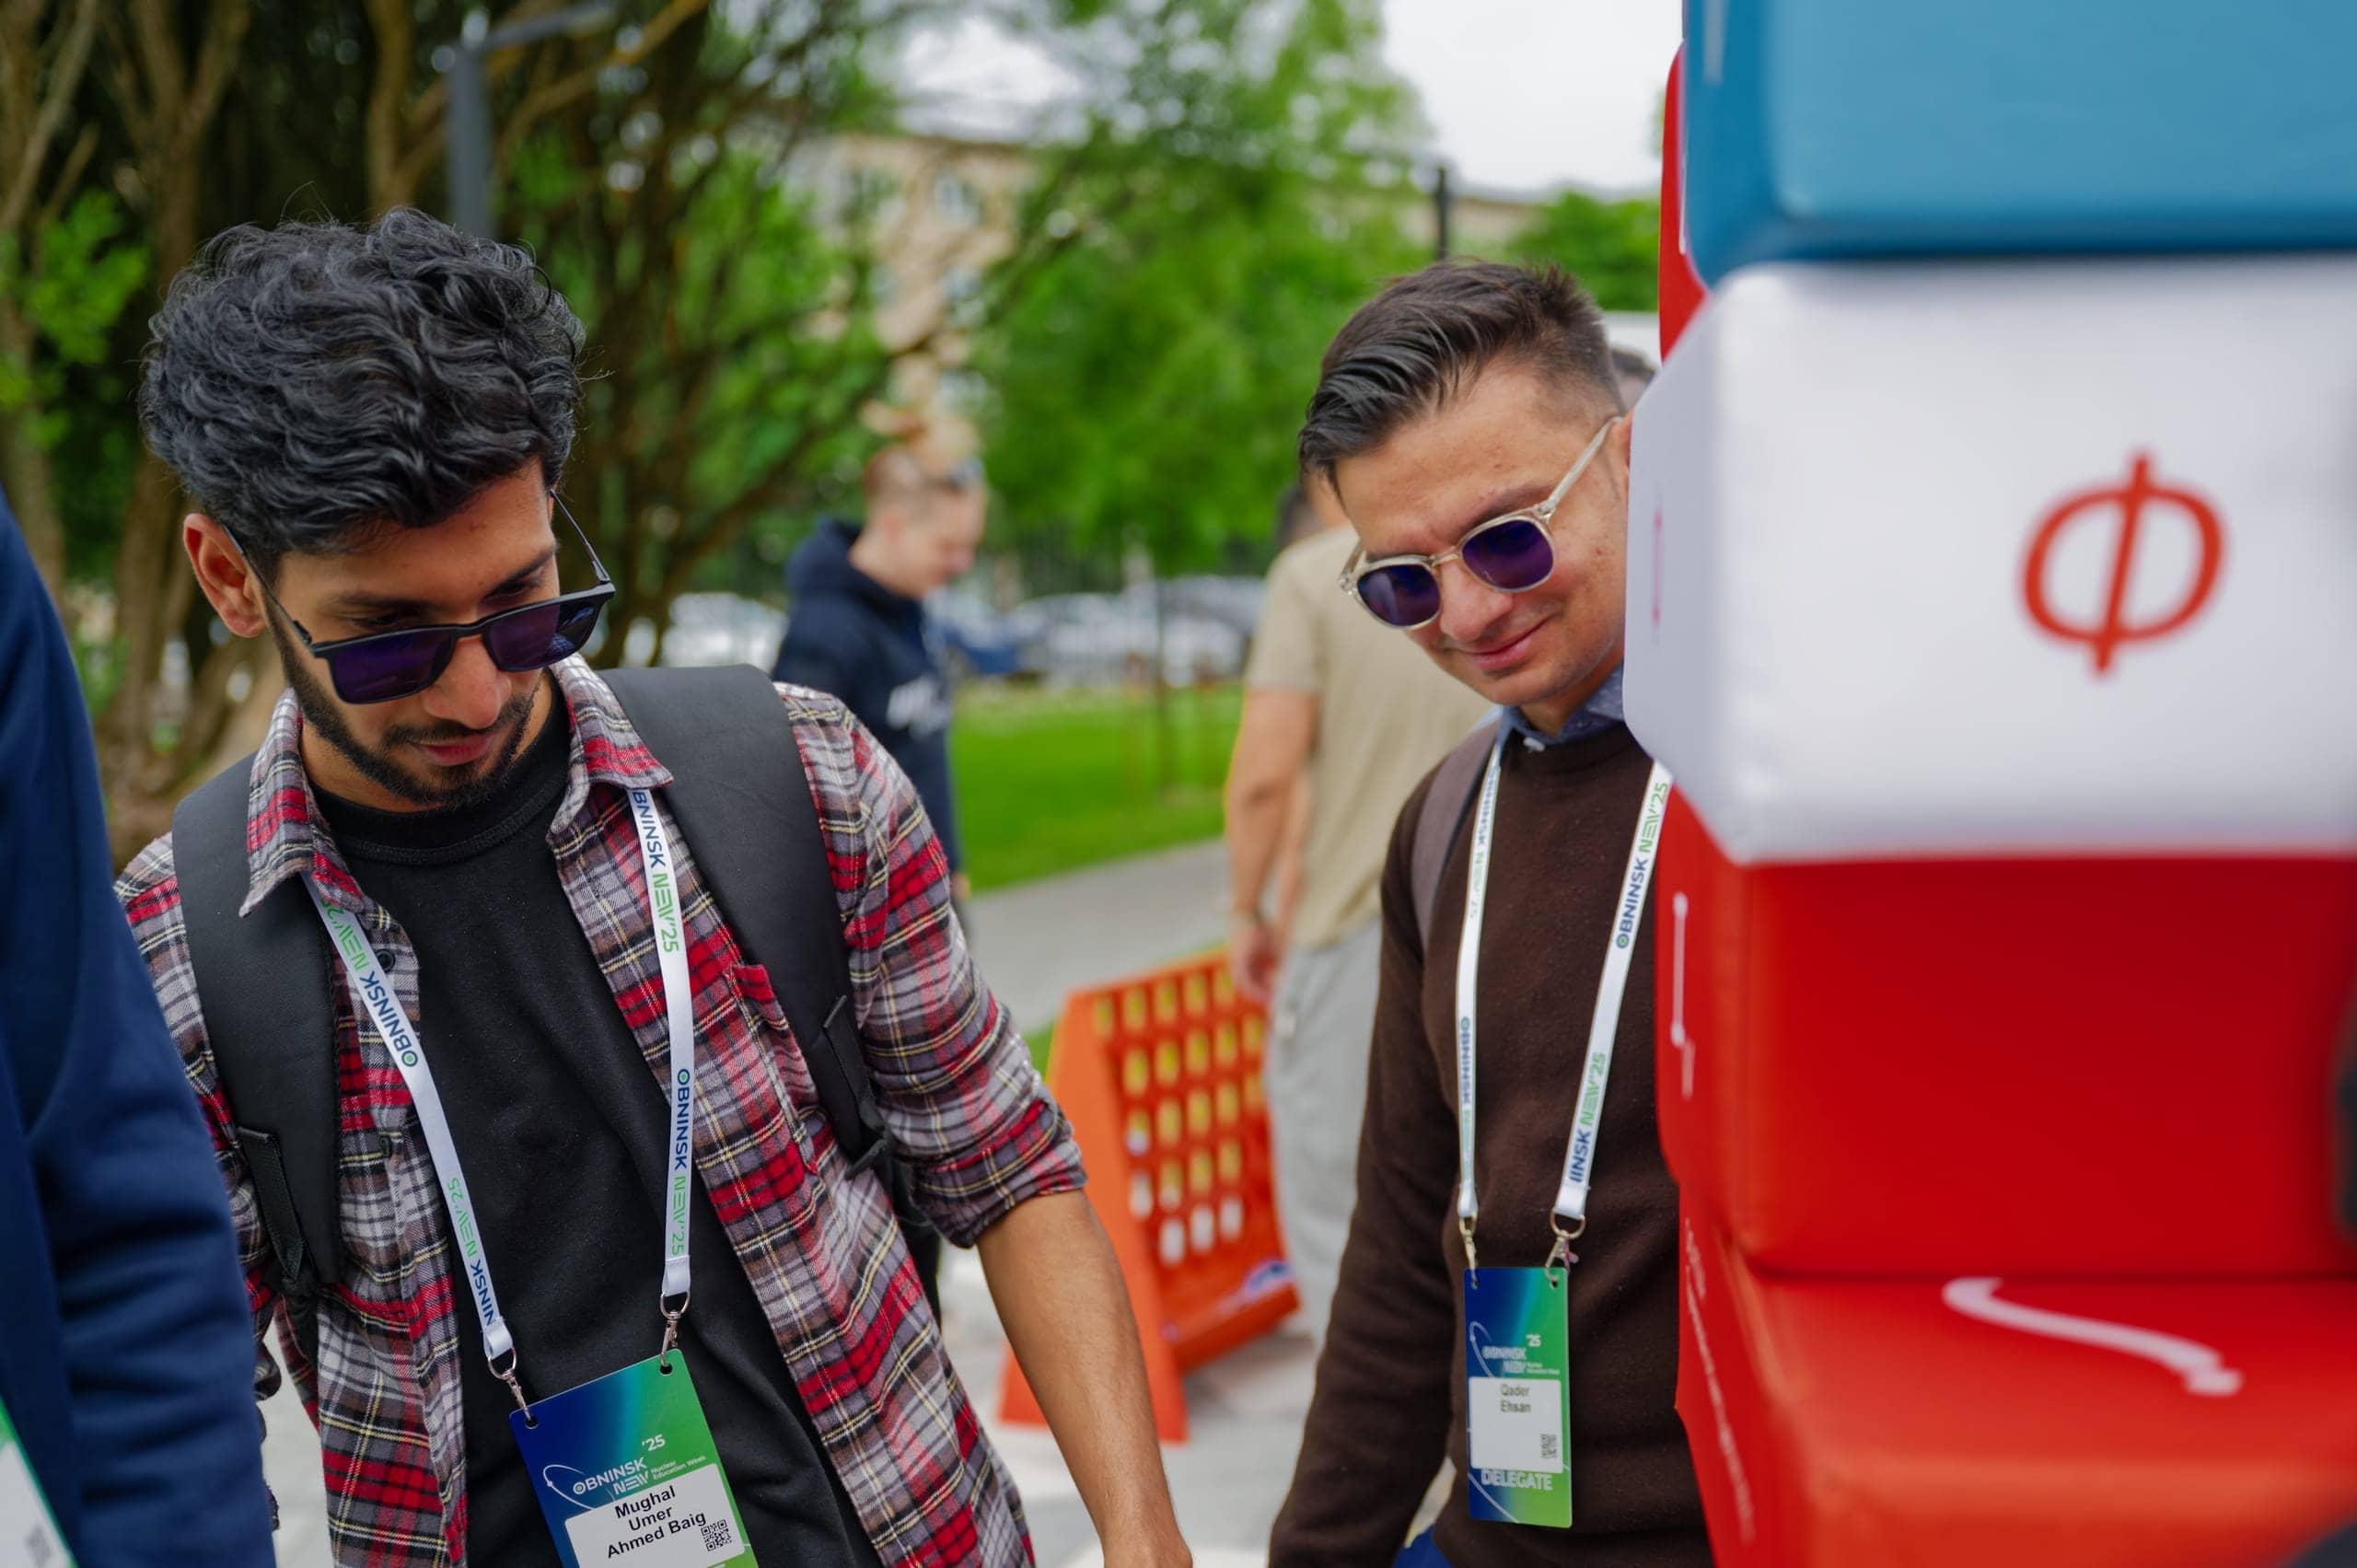
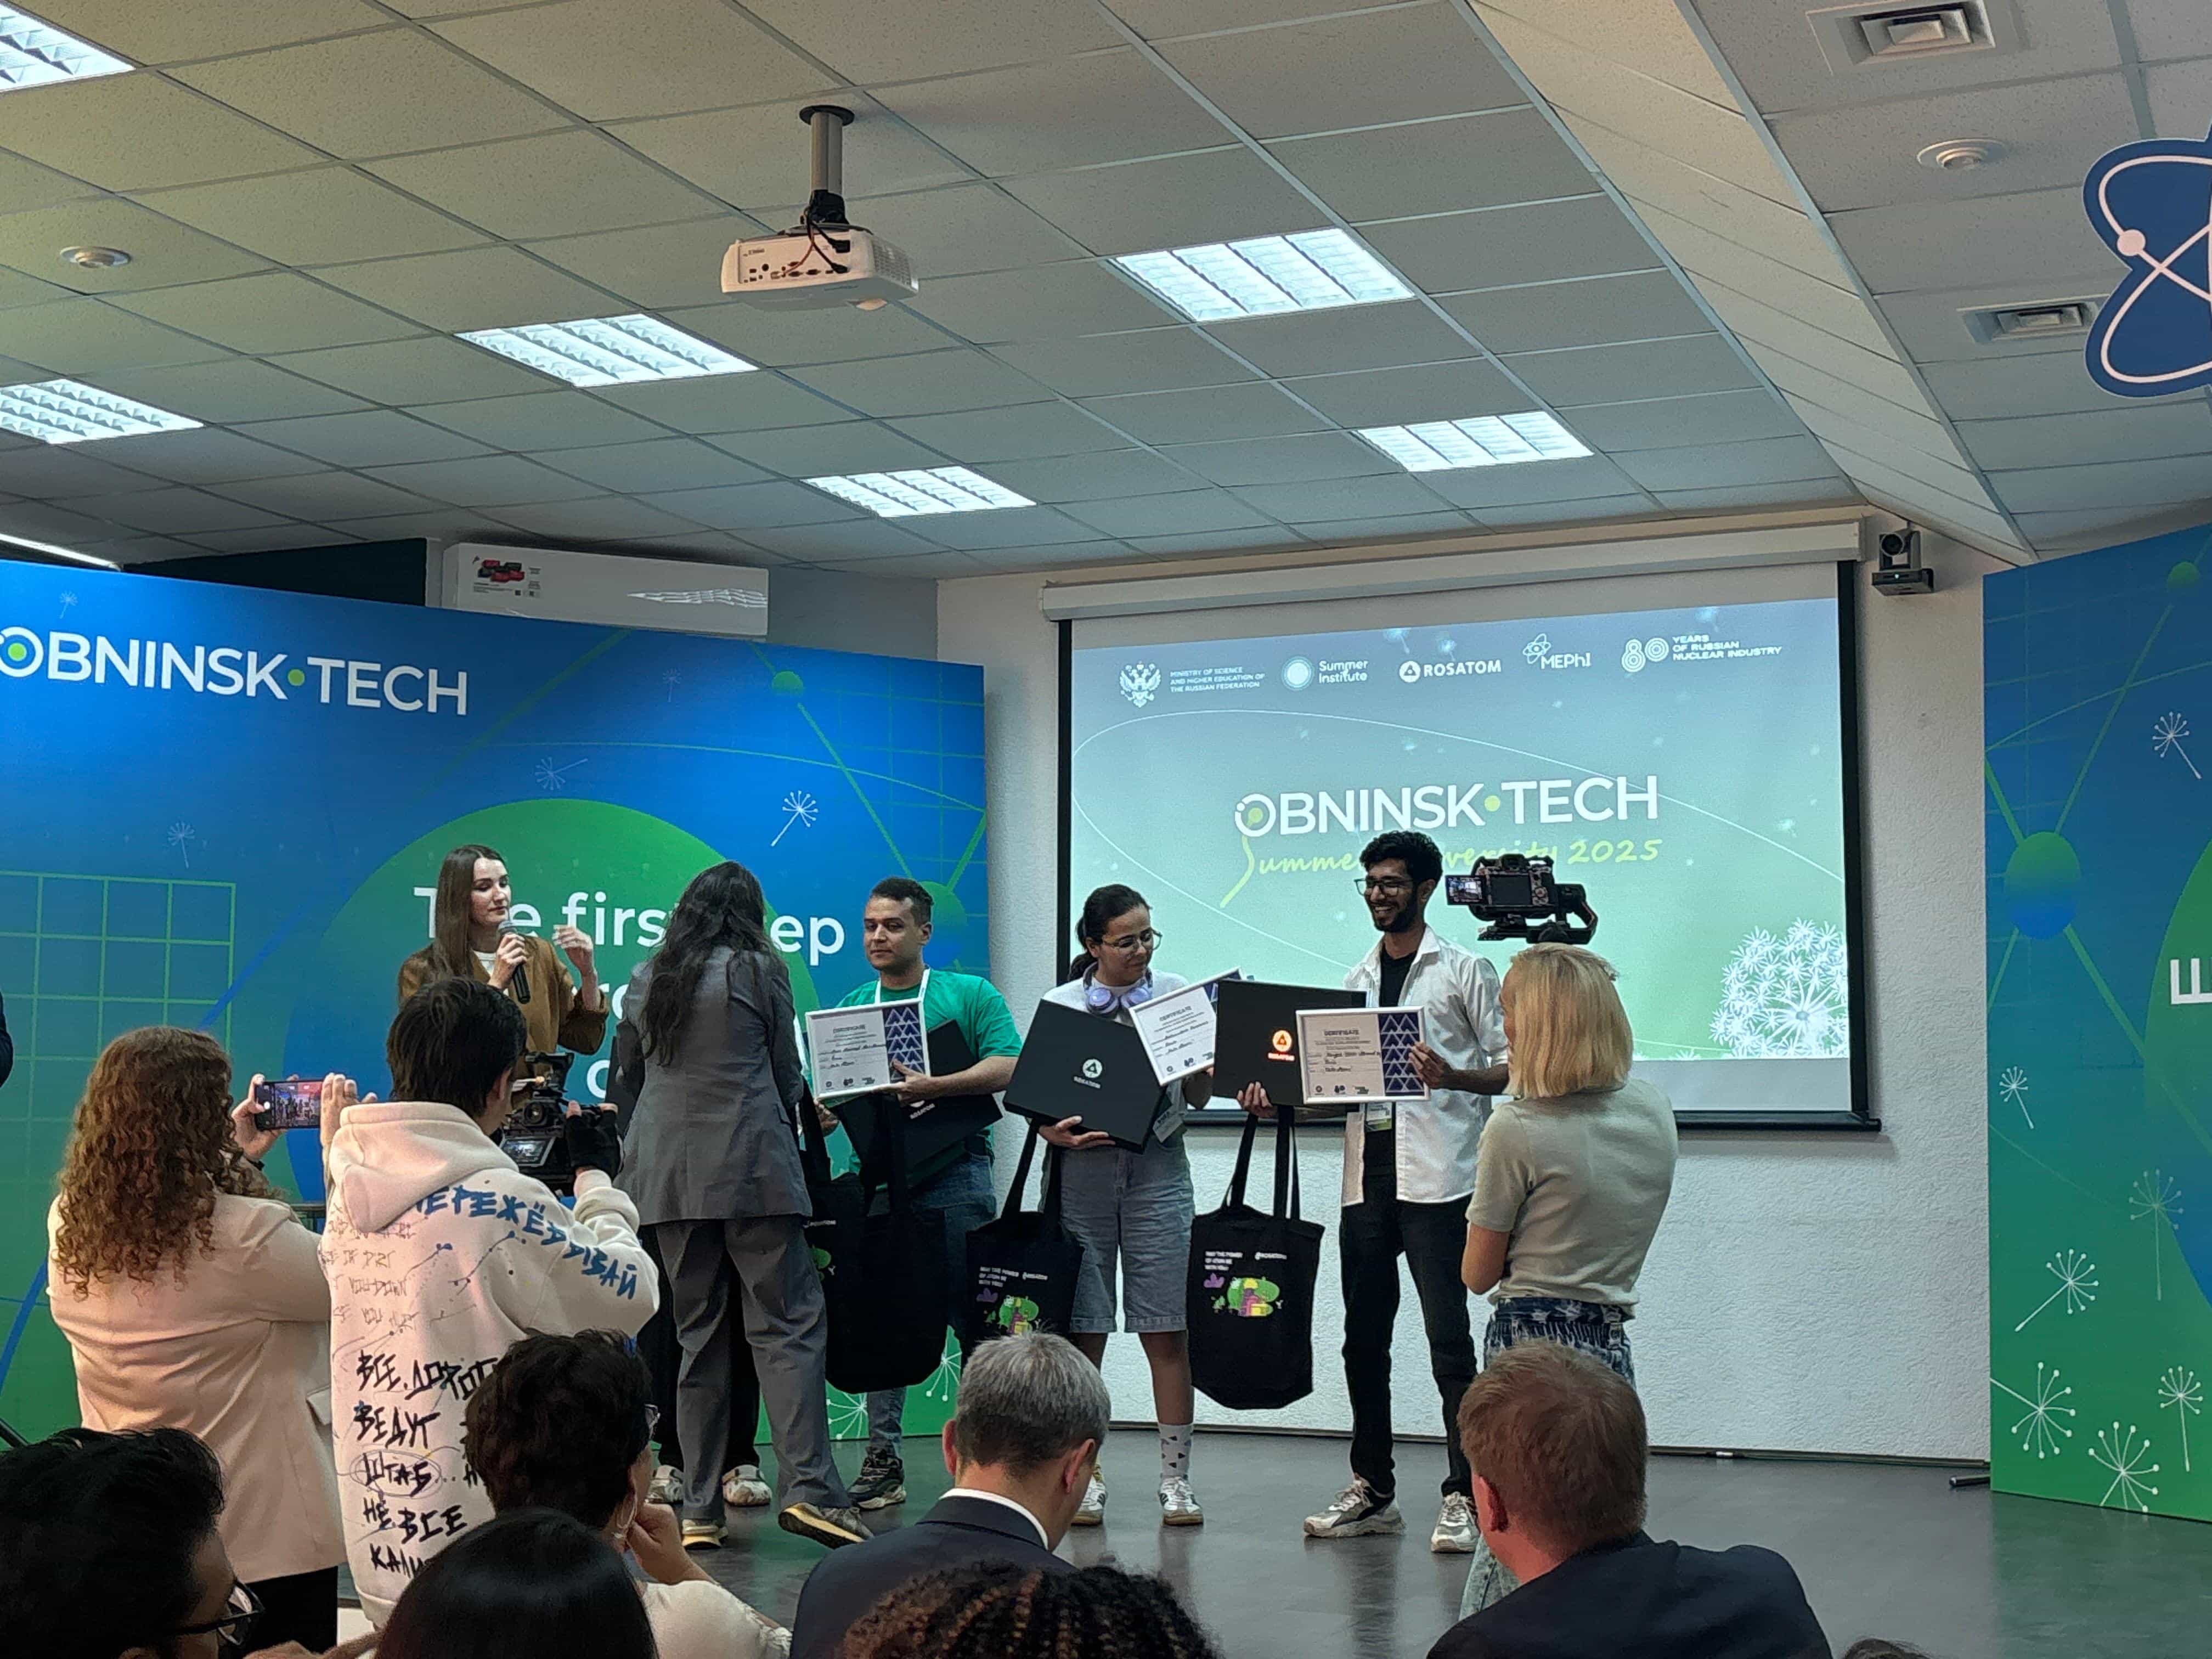
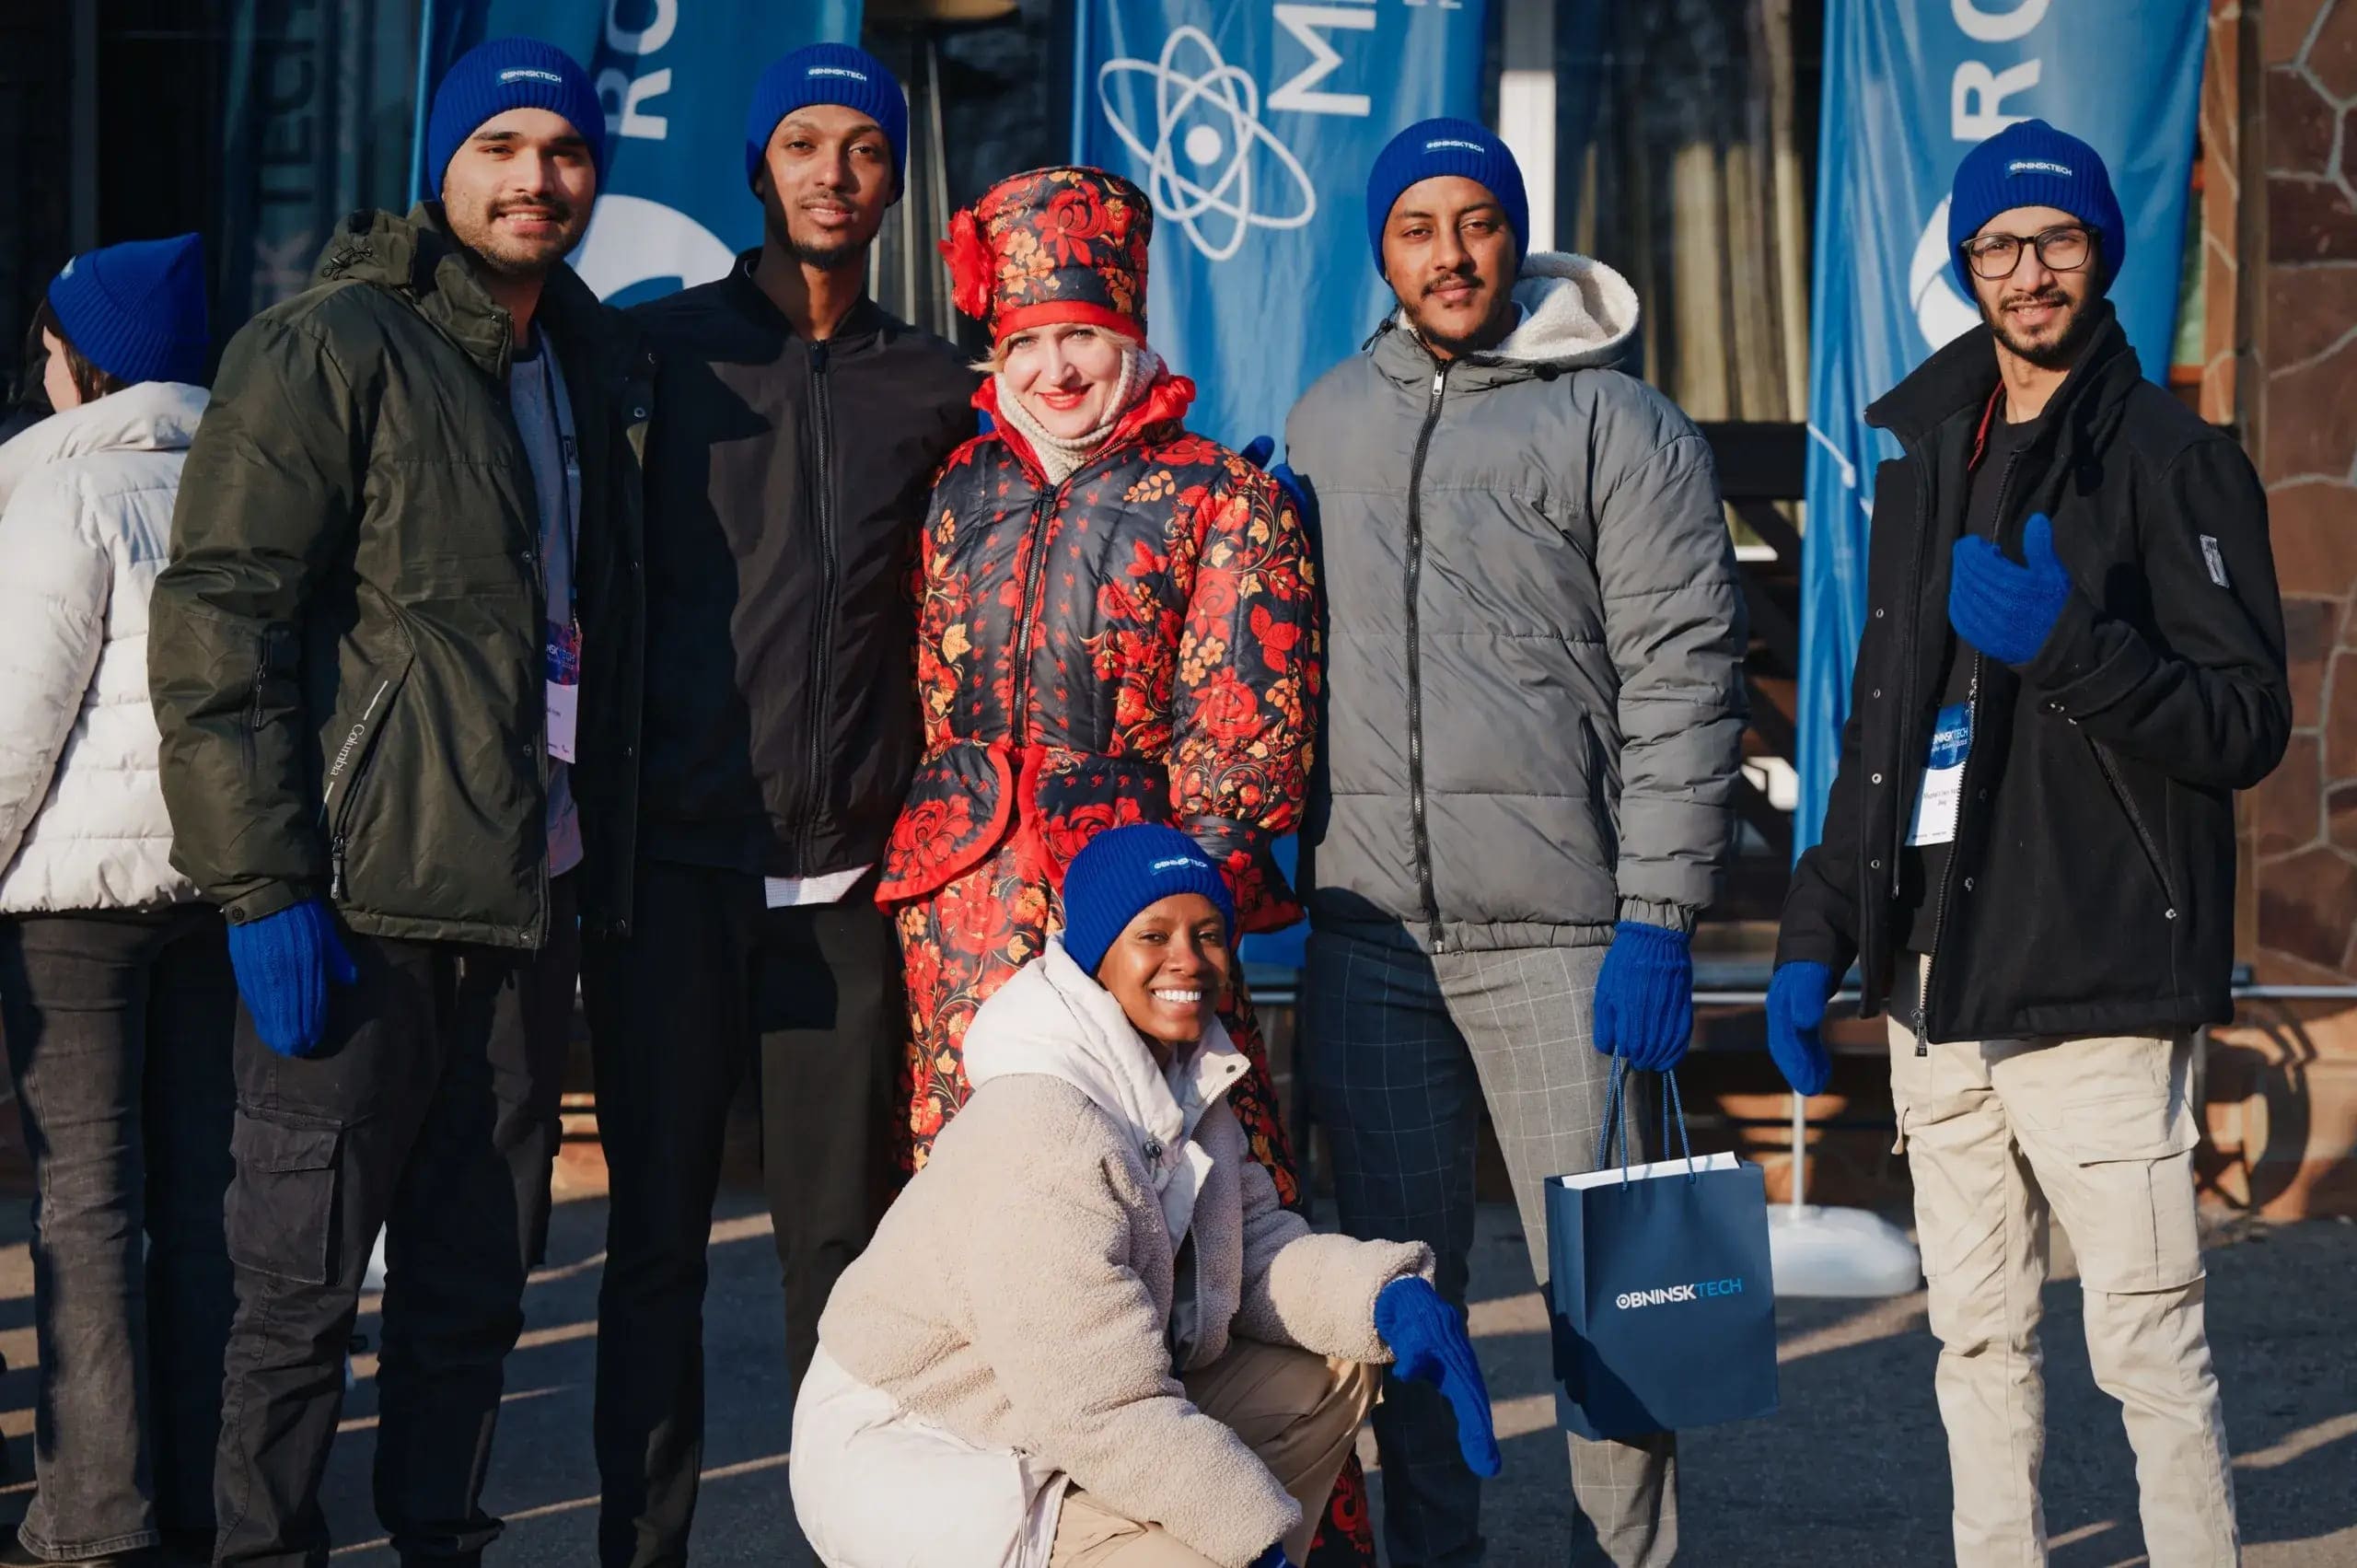
ObninskTech Summer University
ROSATOM & MEPhI · Obninsk, Russia
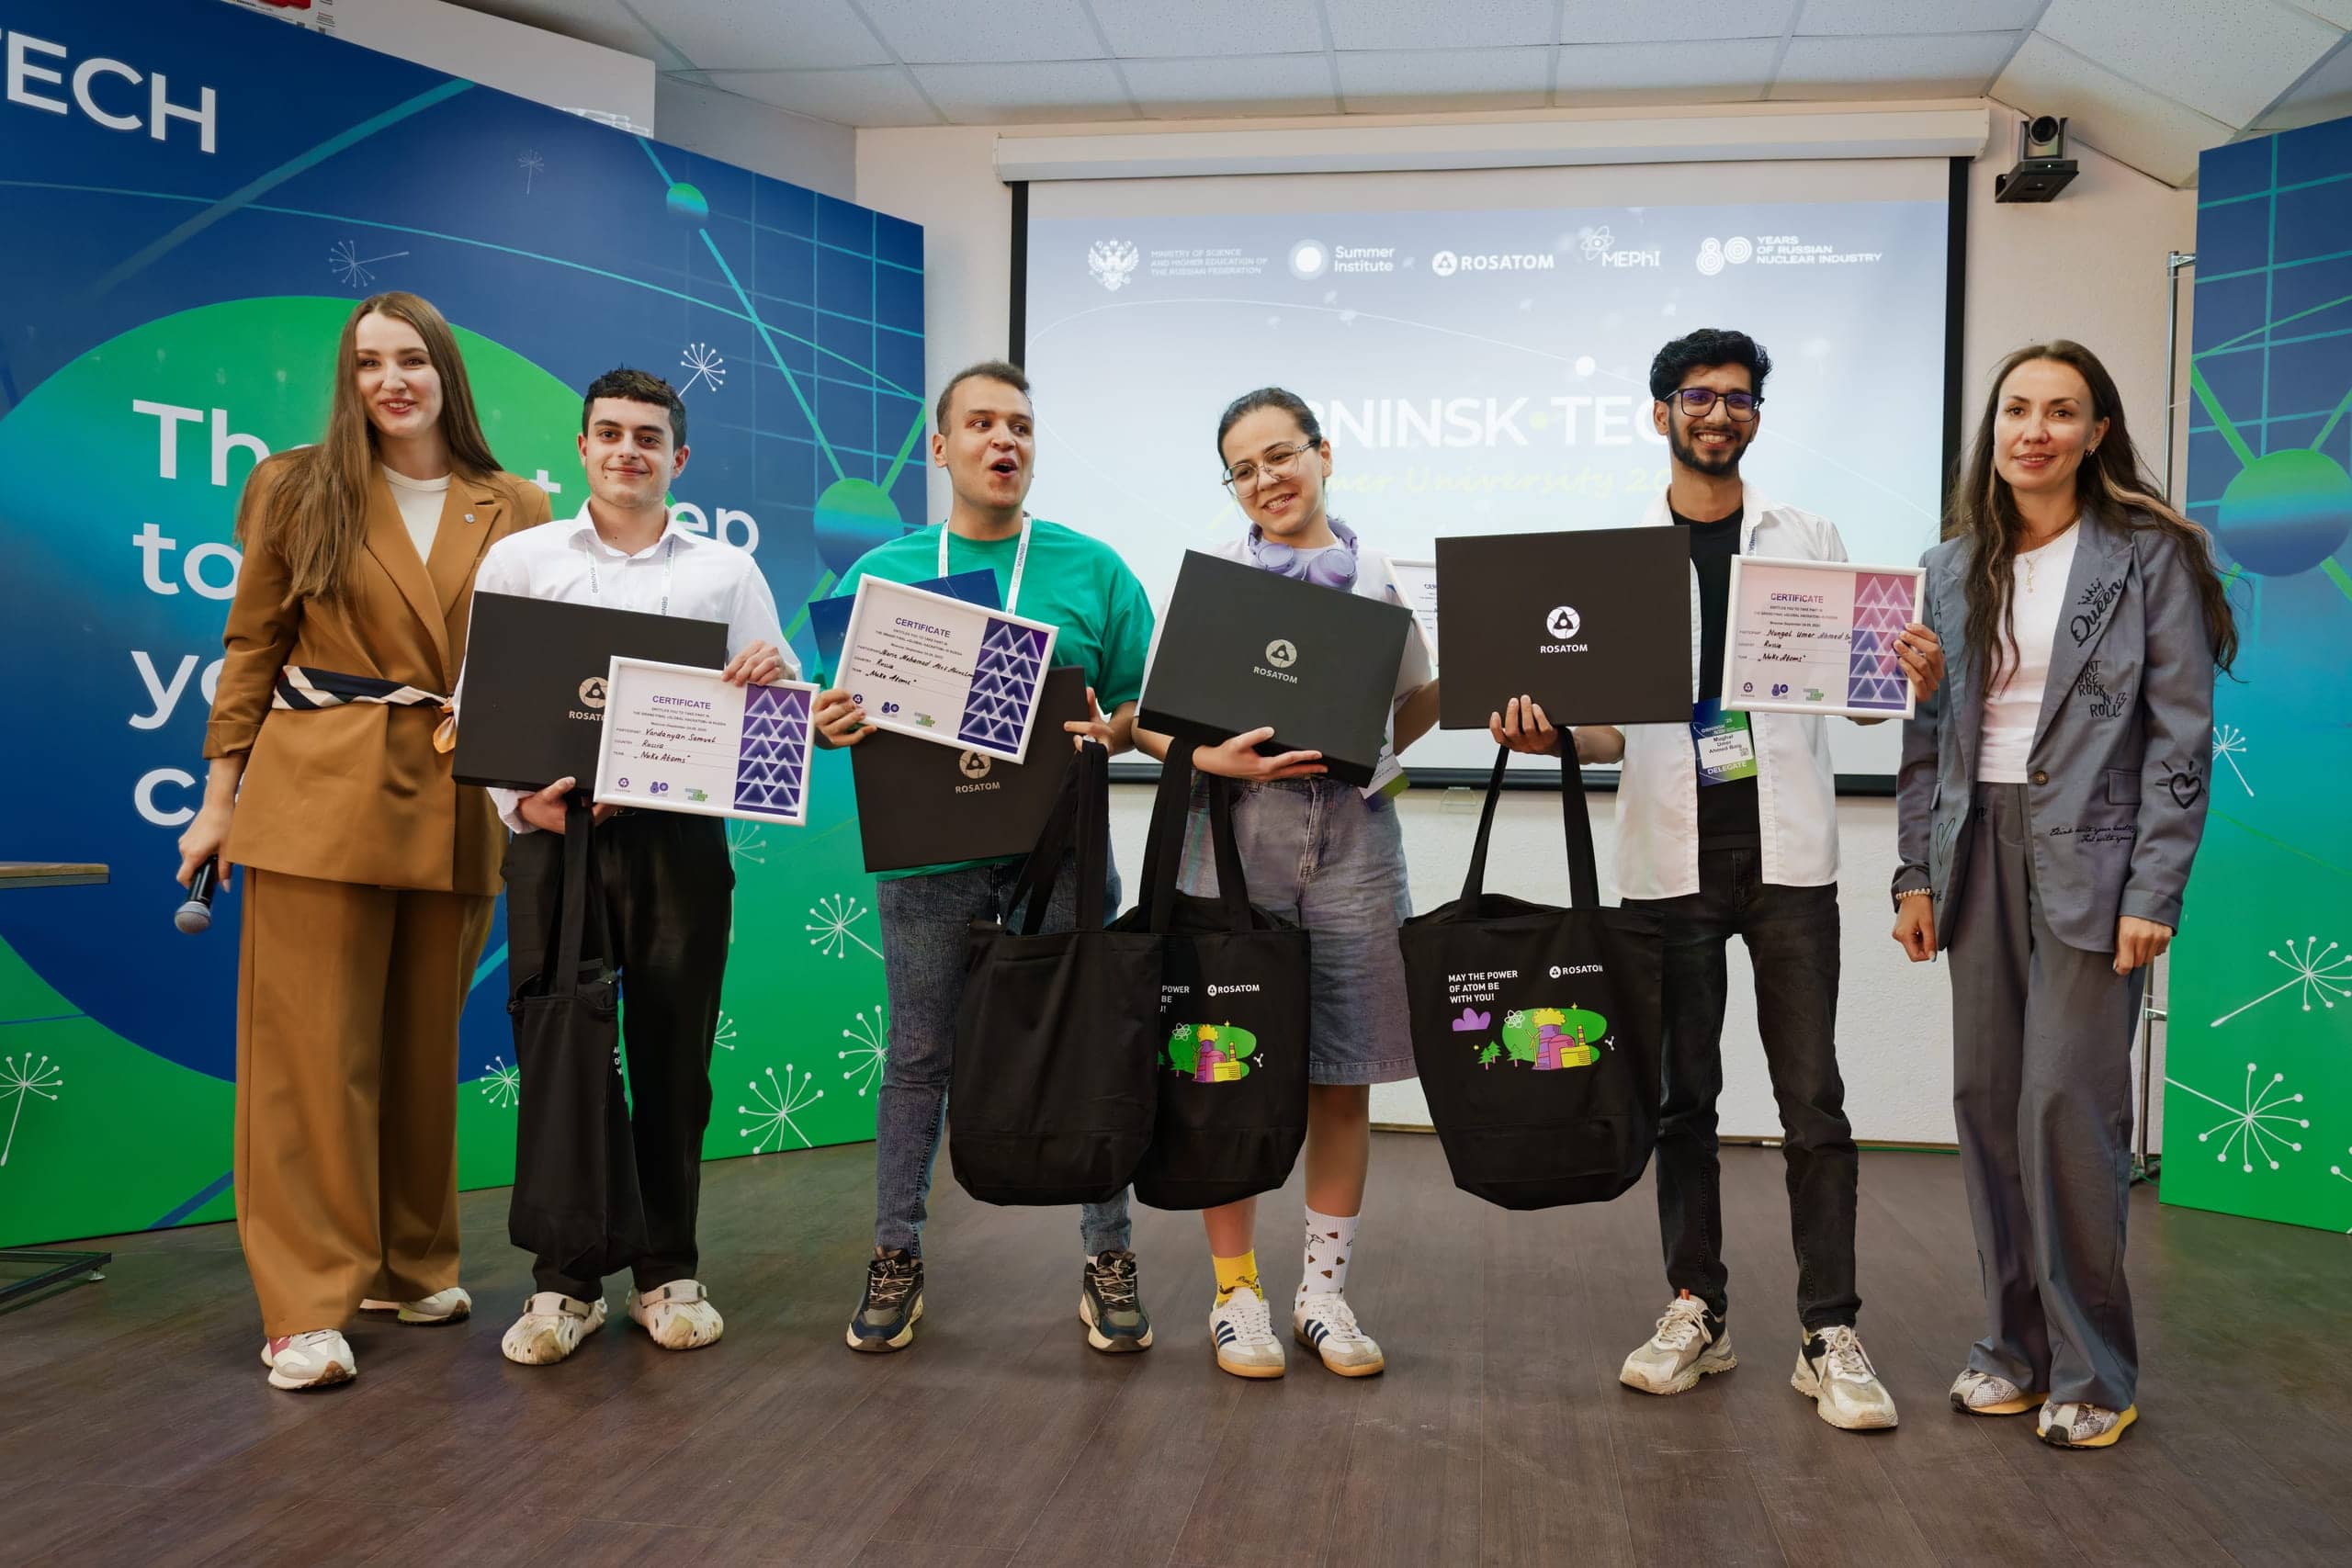
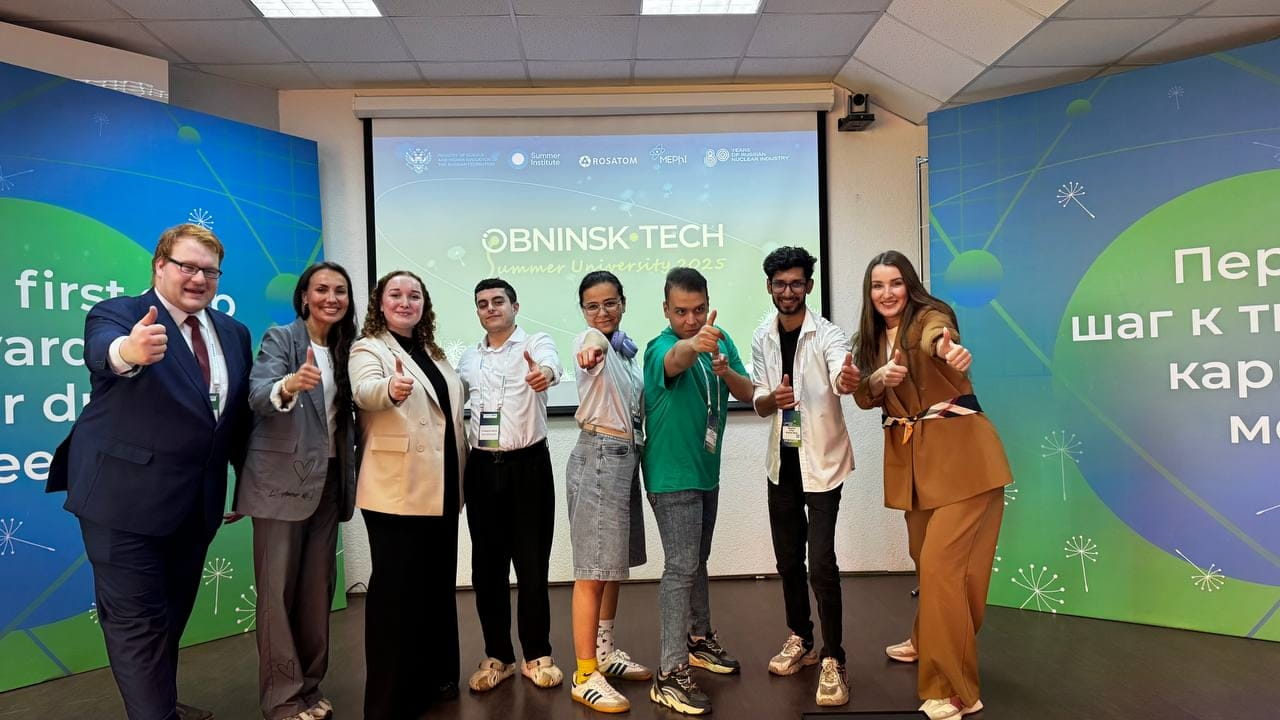
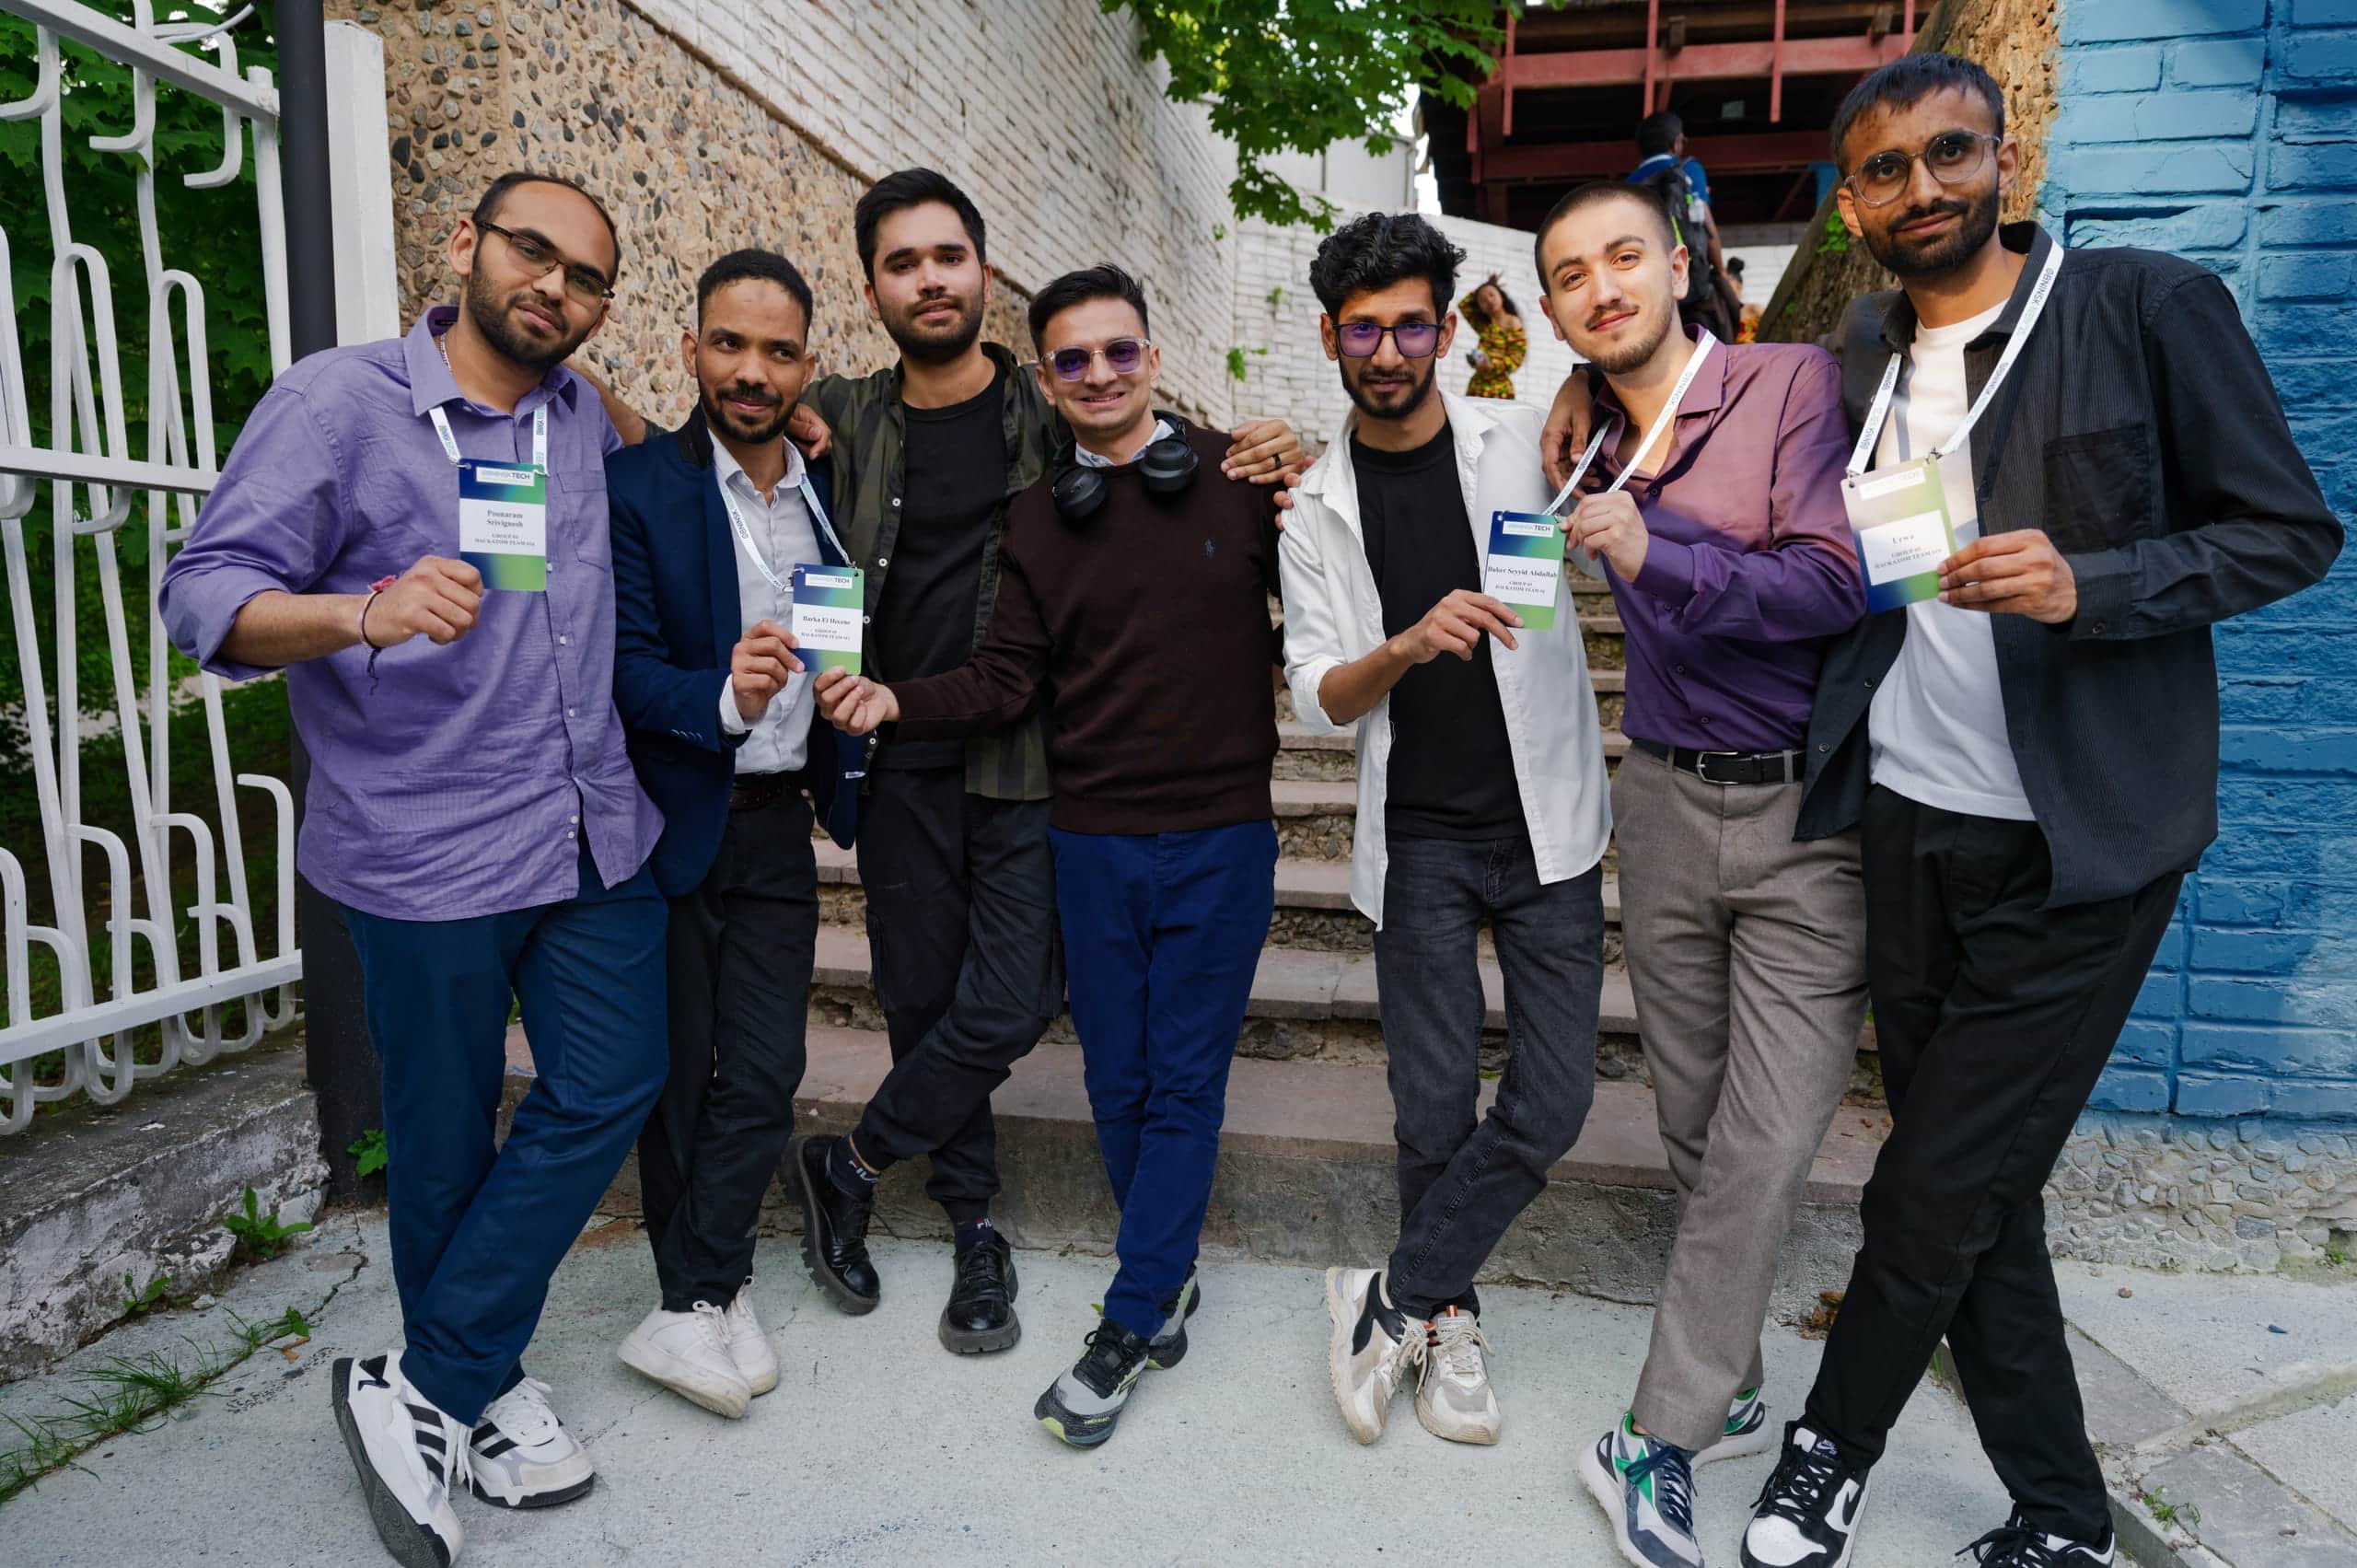
1st — Engineering Hackathon 1st — Atomic Triathlon
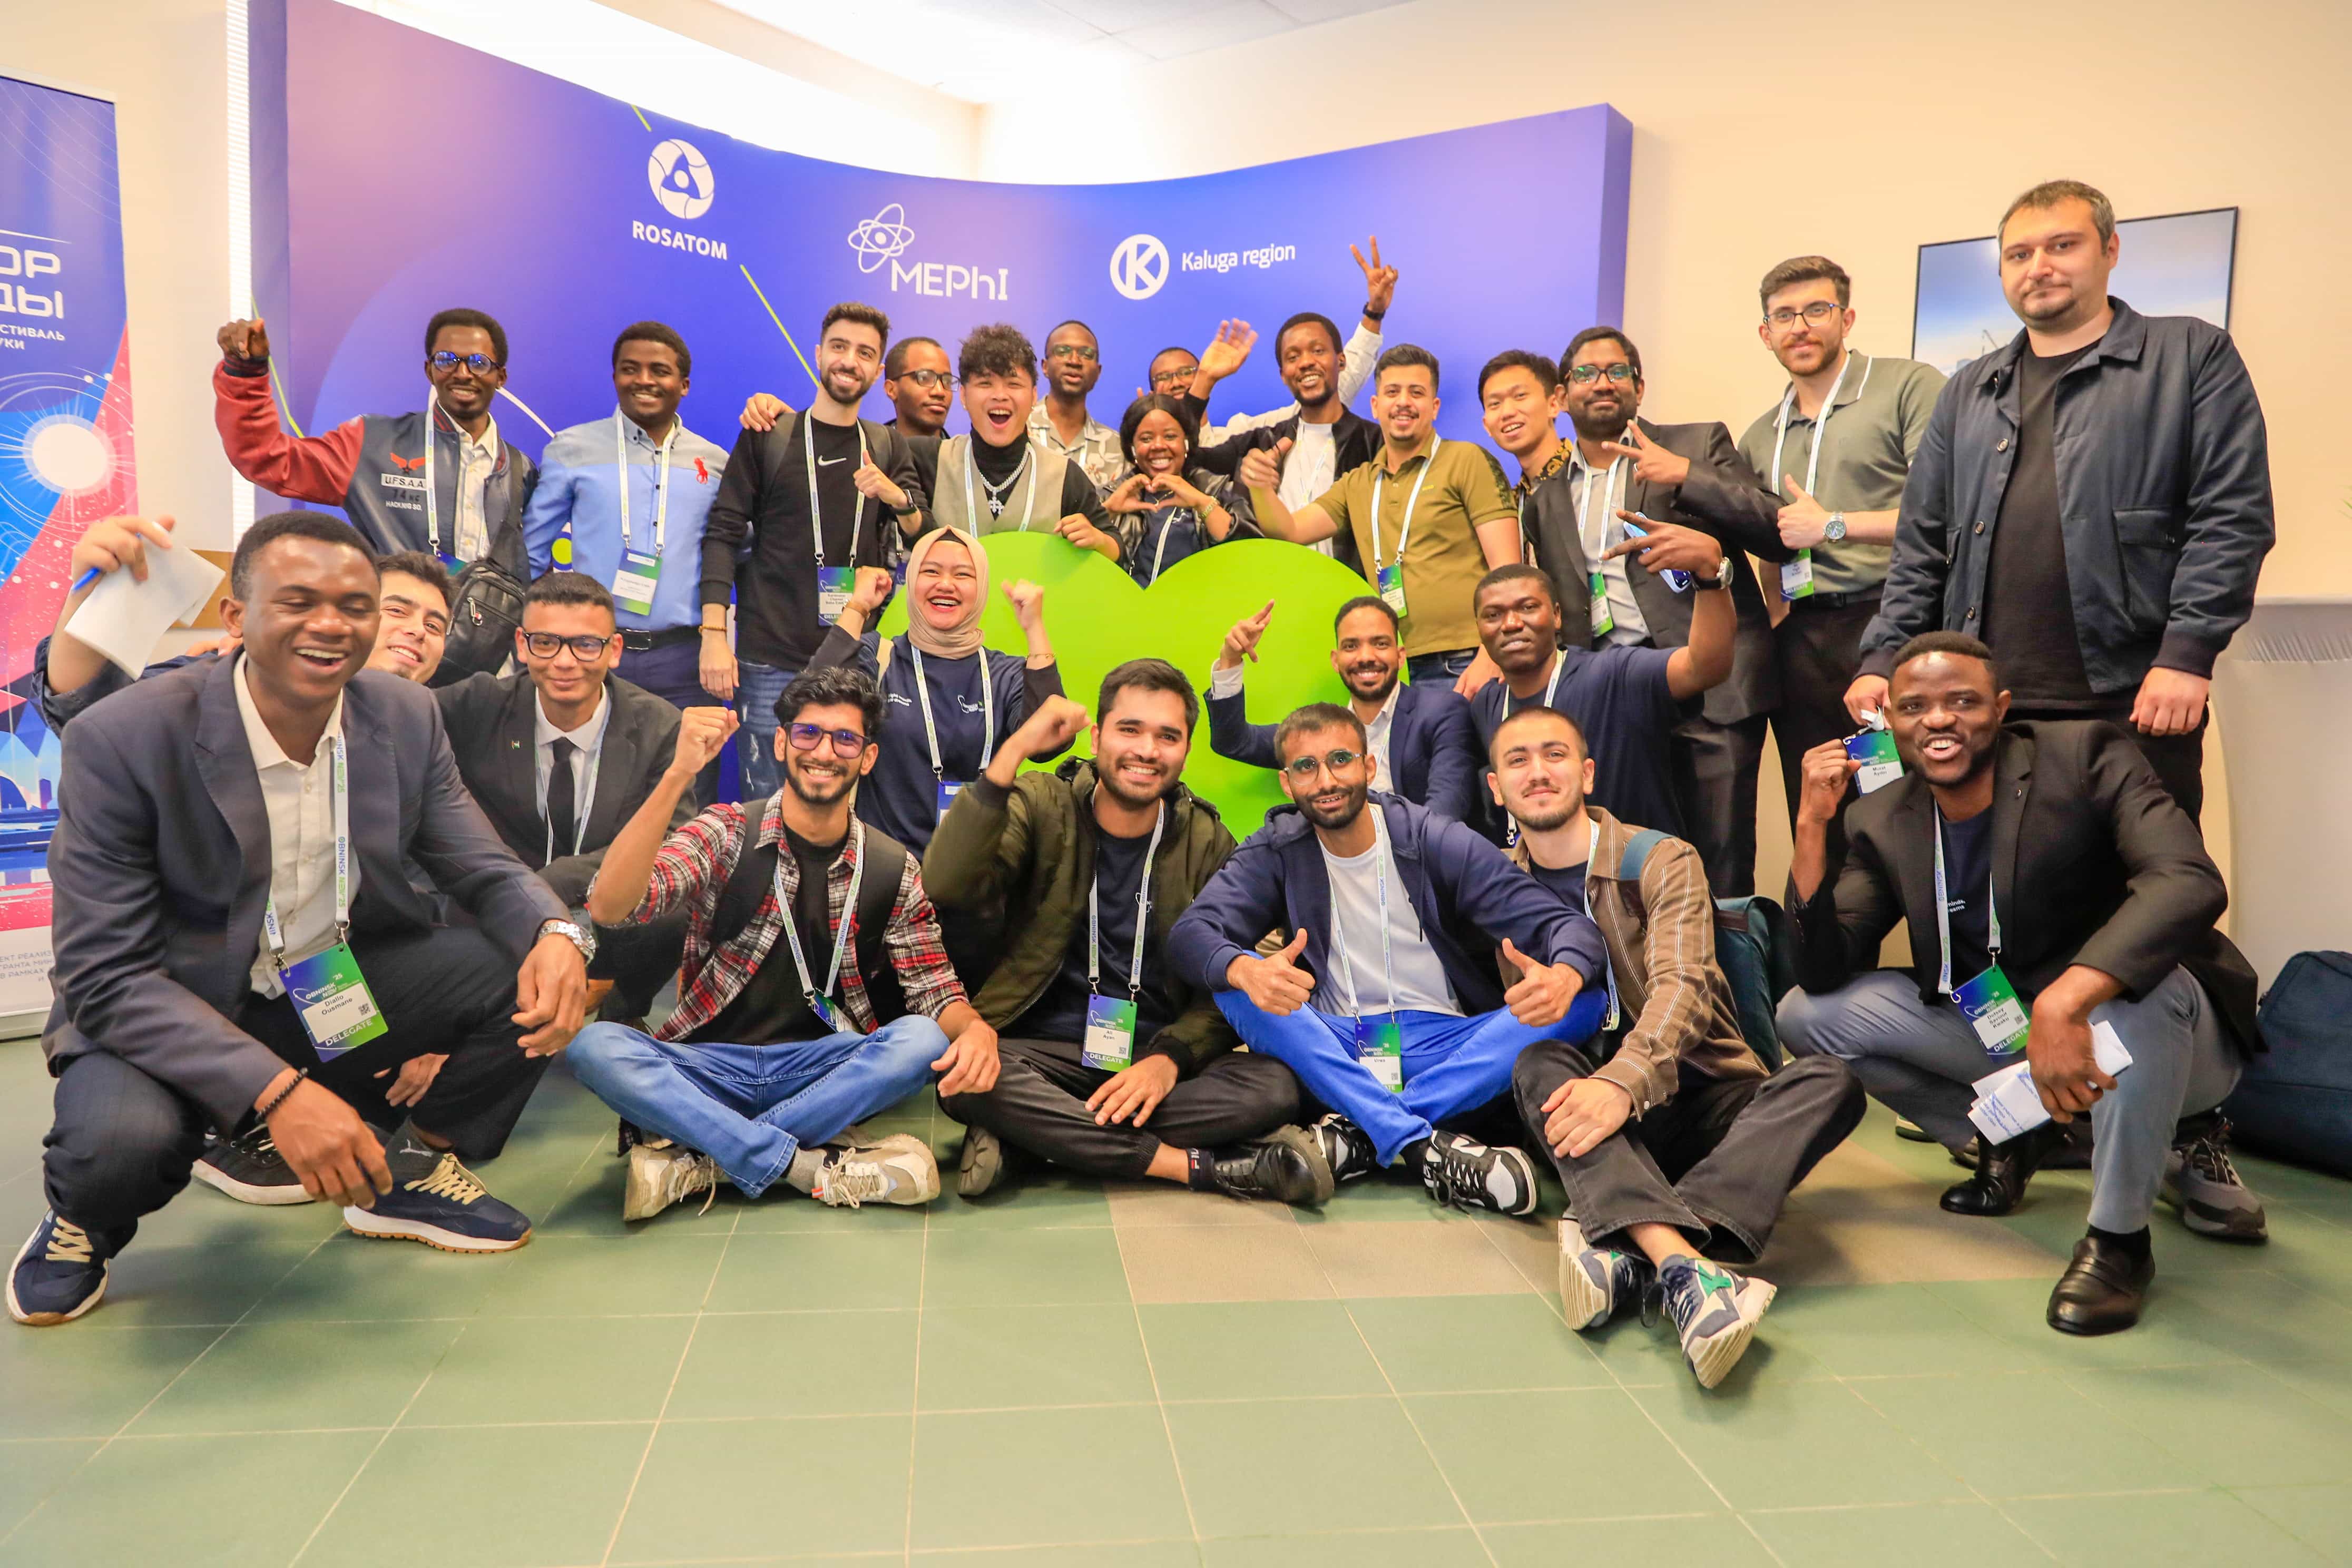
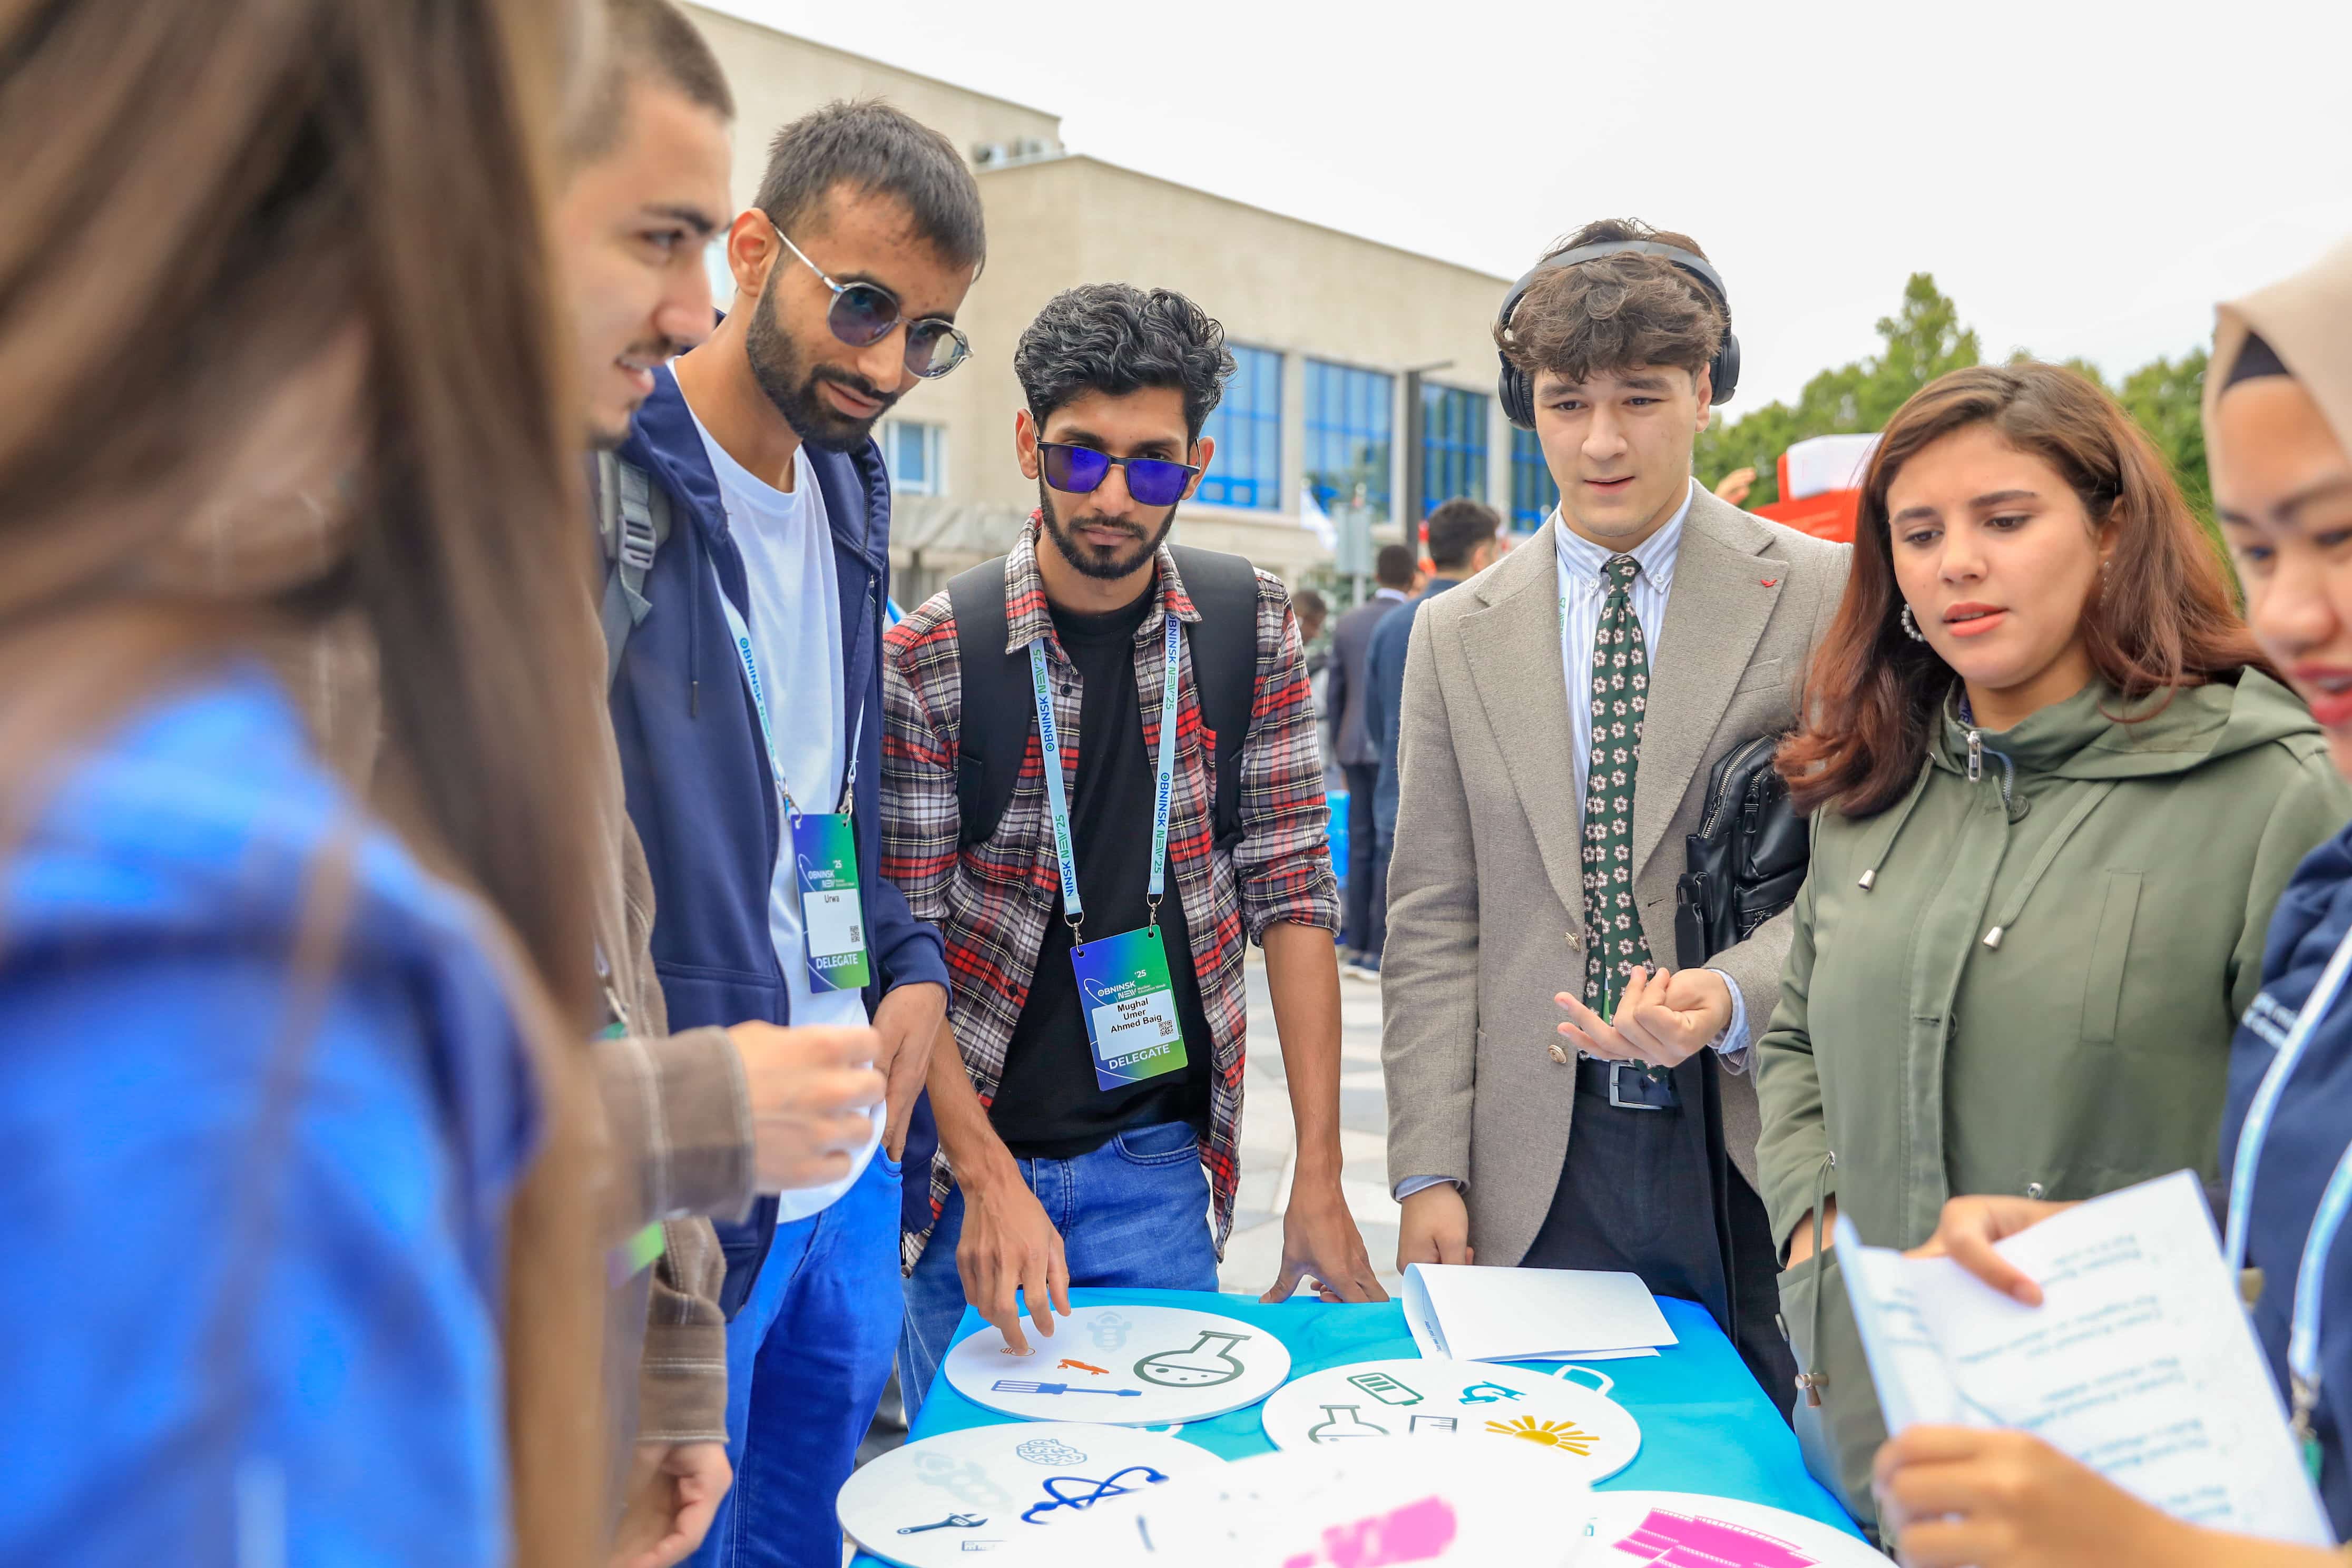
Designed an interactive website with chatbot integration for peaceful nuclear technology education. Won Atomic Triathlon competing alongside students from 40+ countries, demonstrating strategic thinking and problem-solving.
08 February 2025
ObninskTech Winter School
ROSATOM & MEPhI · Obninsk, Russia
3rd — Engineering Hackathon
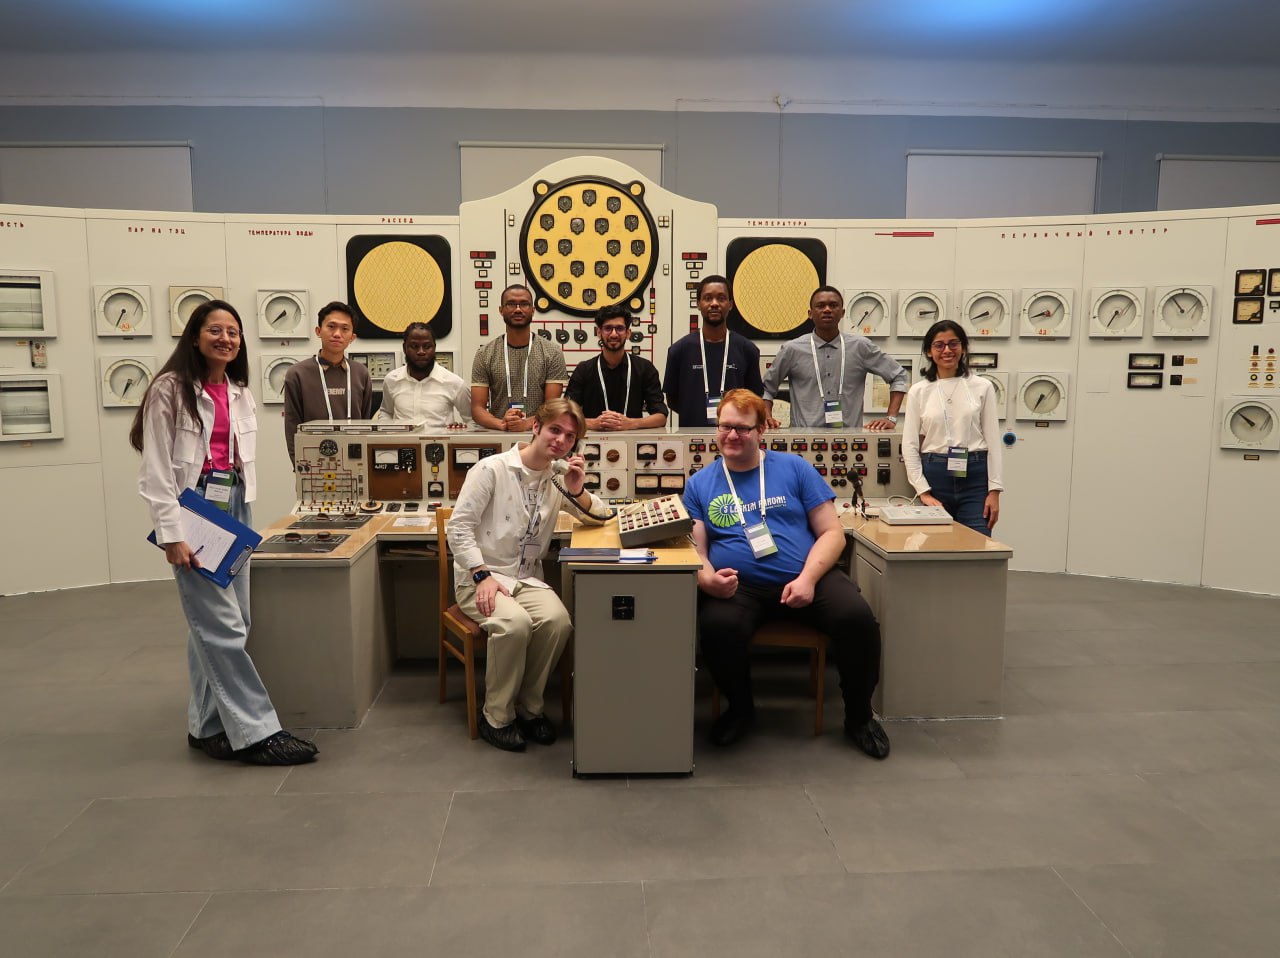
Developed innovative engineering solutions in a competitive multidisciplinary environment. Collaborated with professionals from 39 countries, gaining hands-on exposure to nuclear technologies and global R&D practices.
28 September 2025
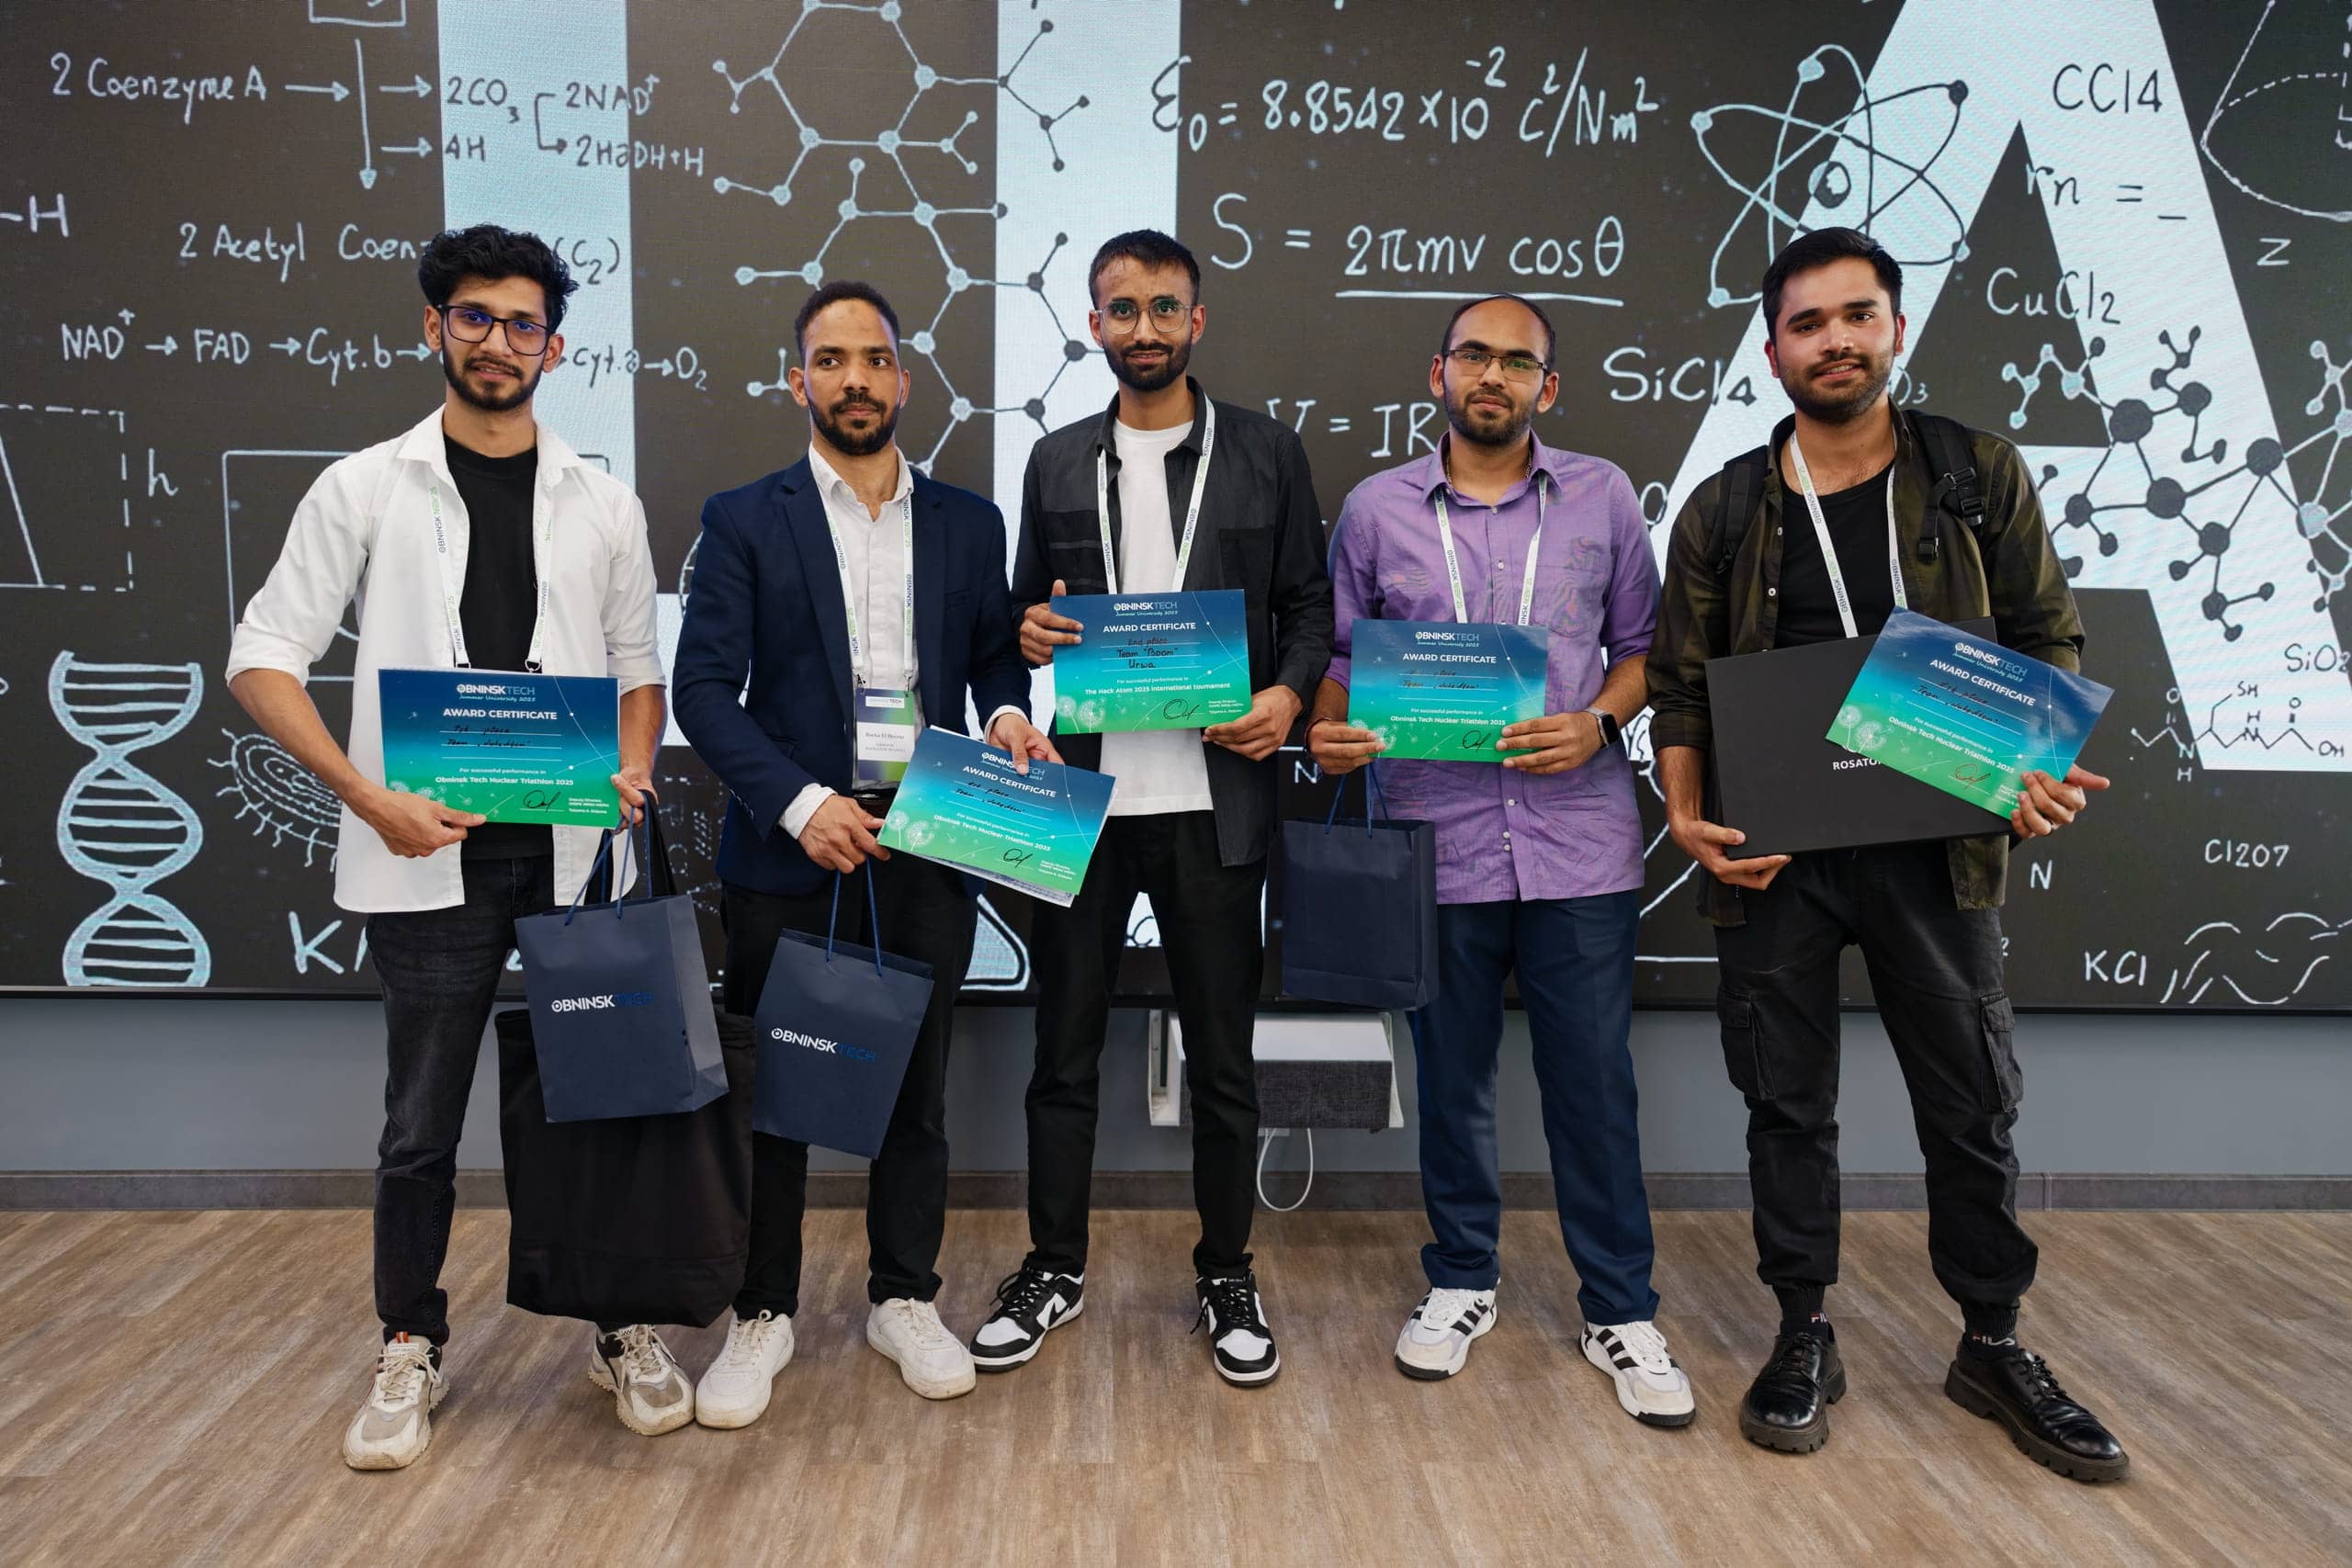
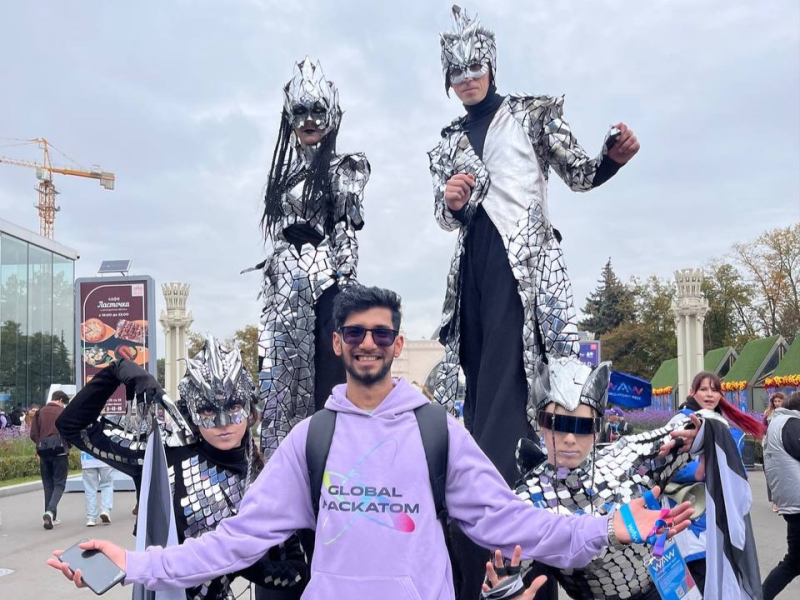
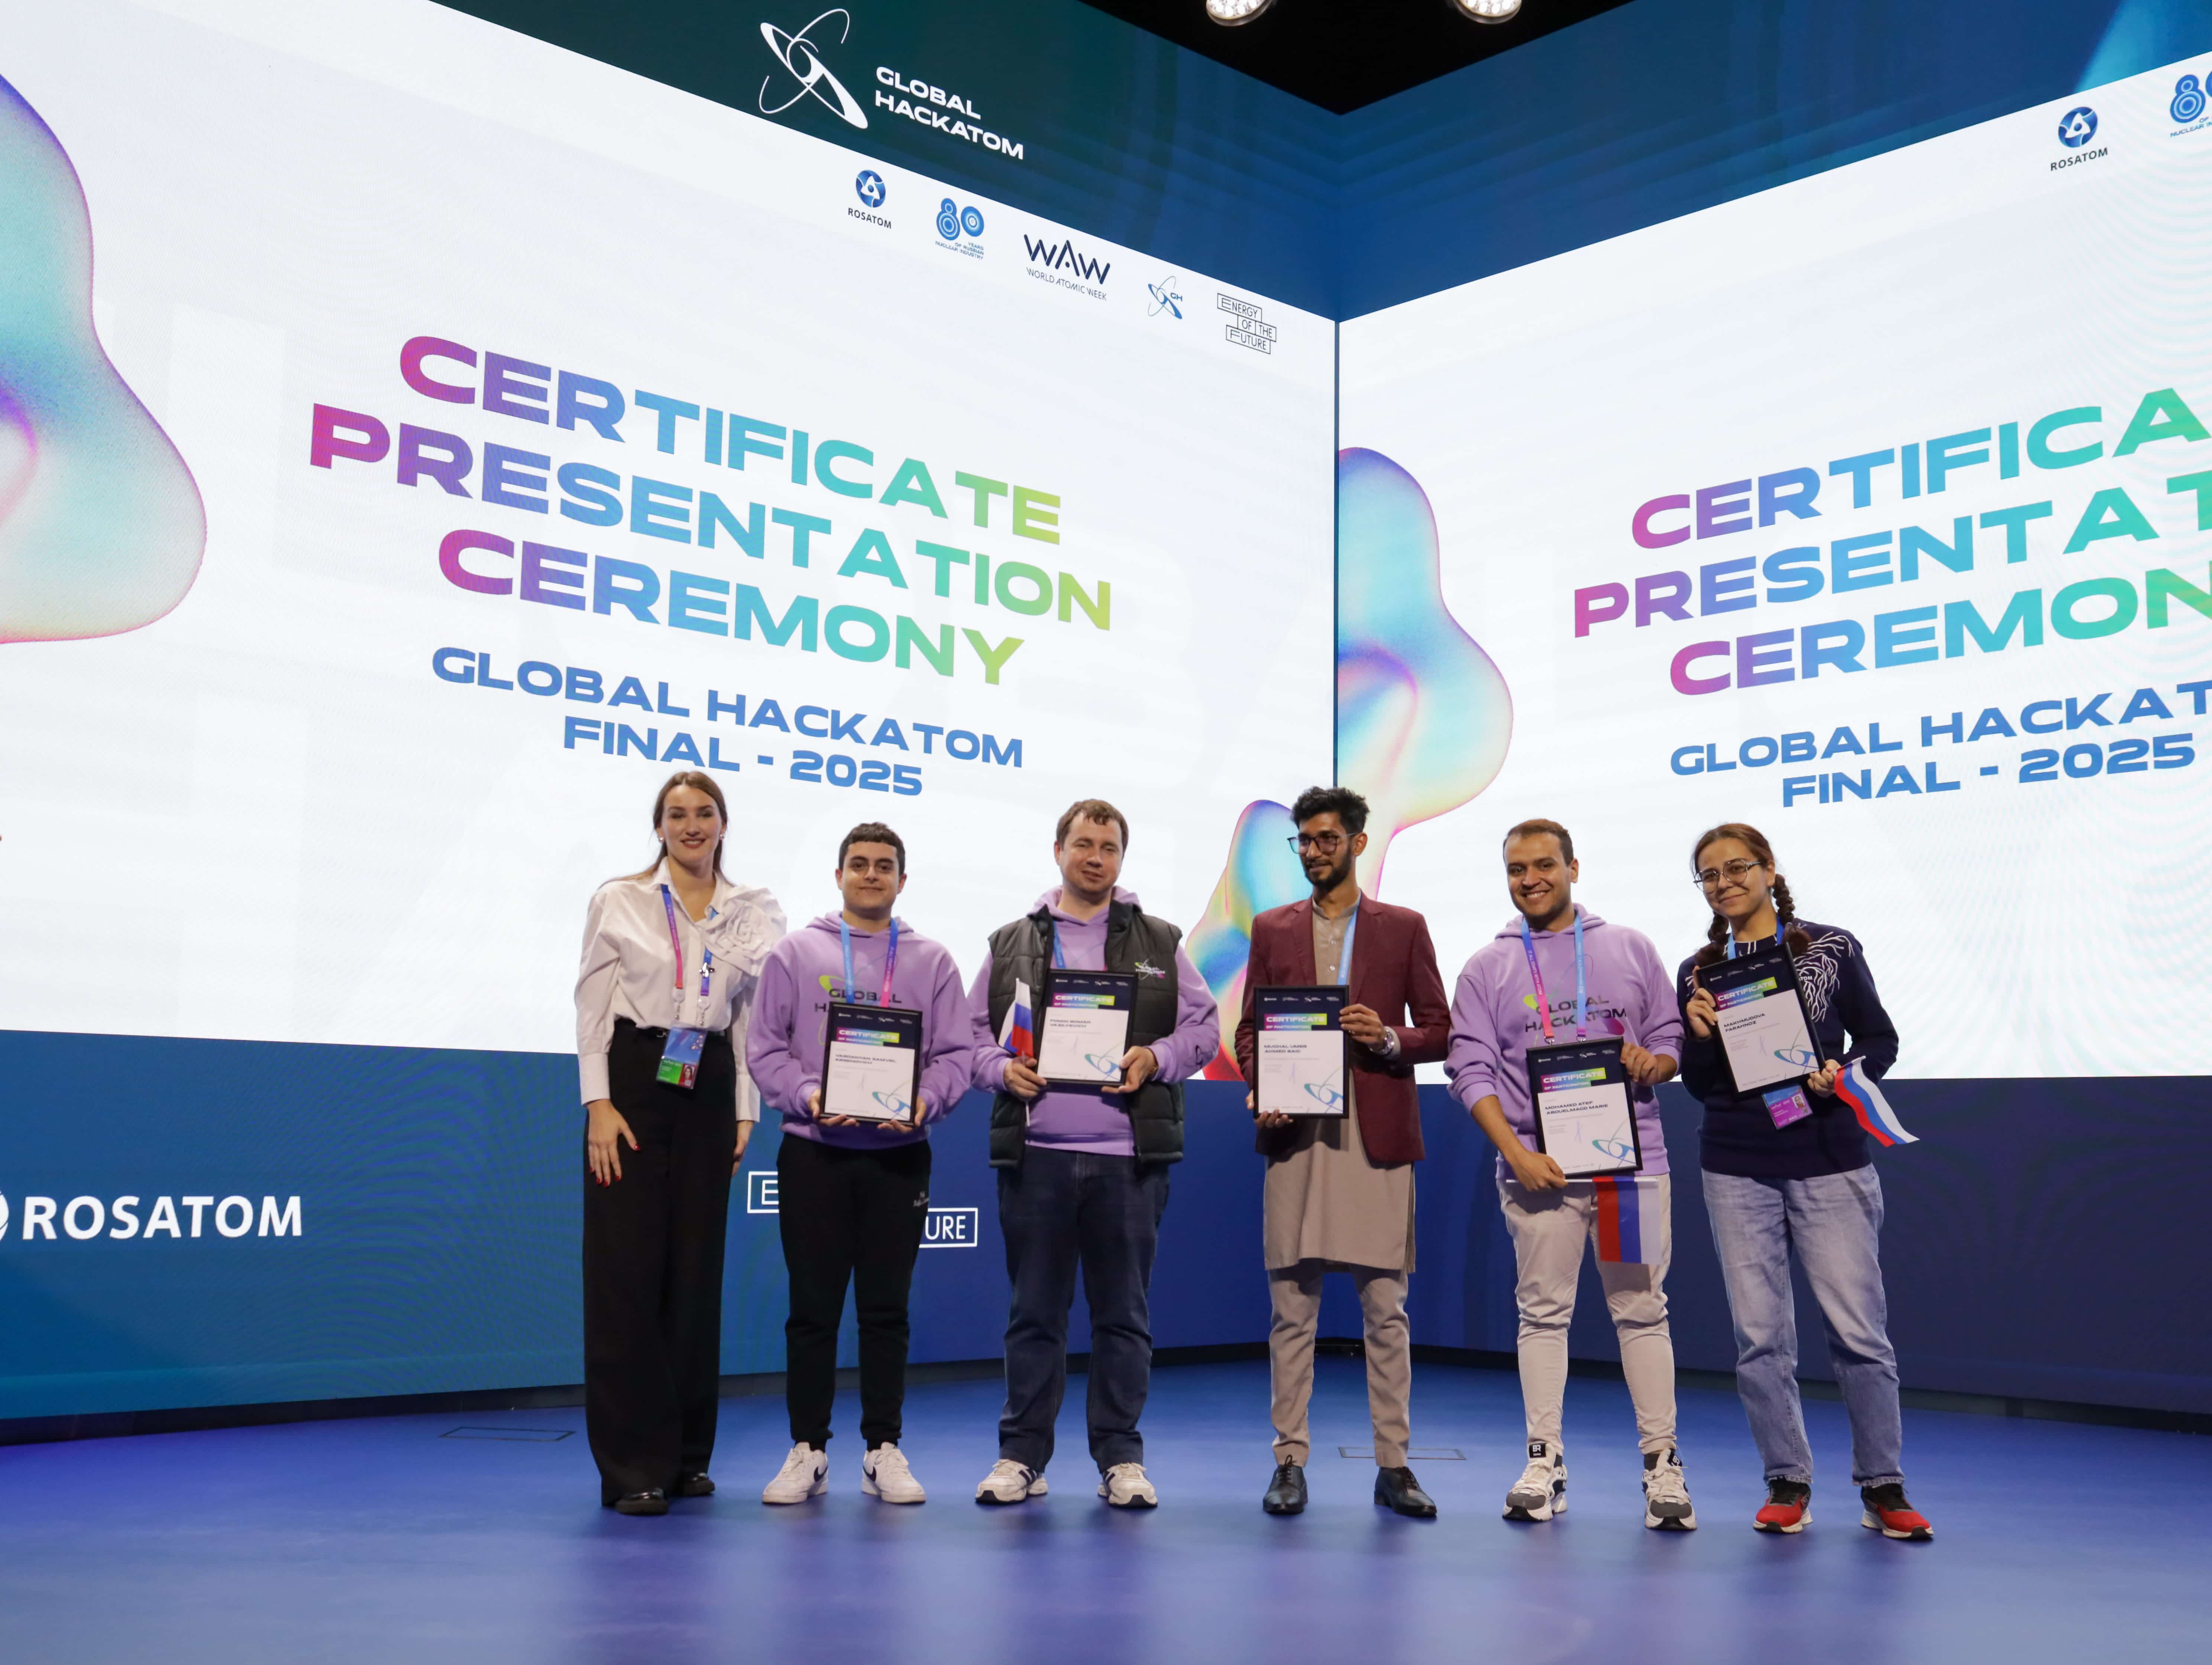
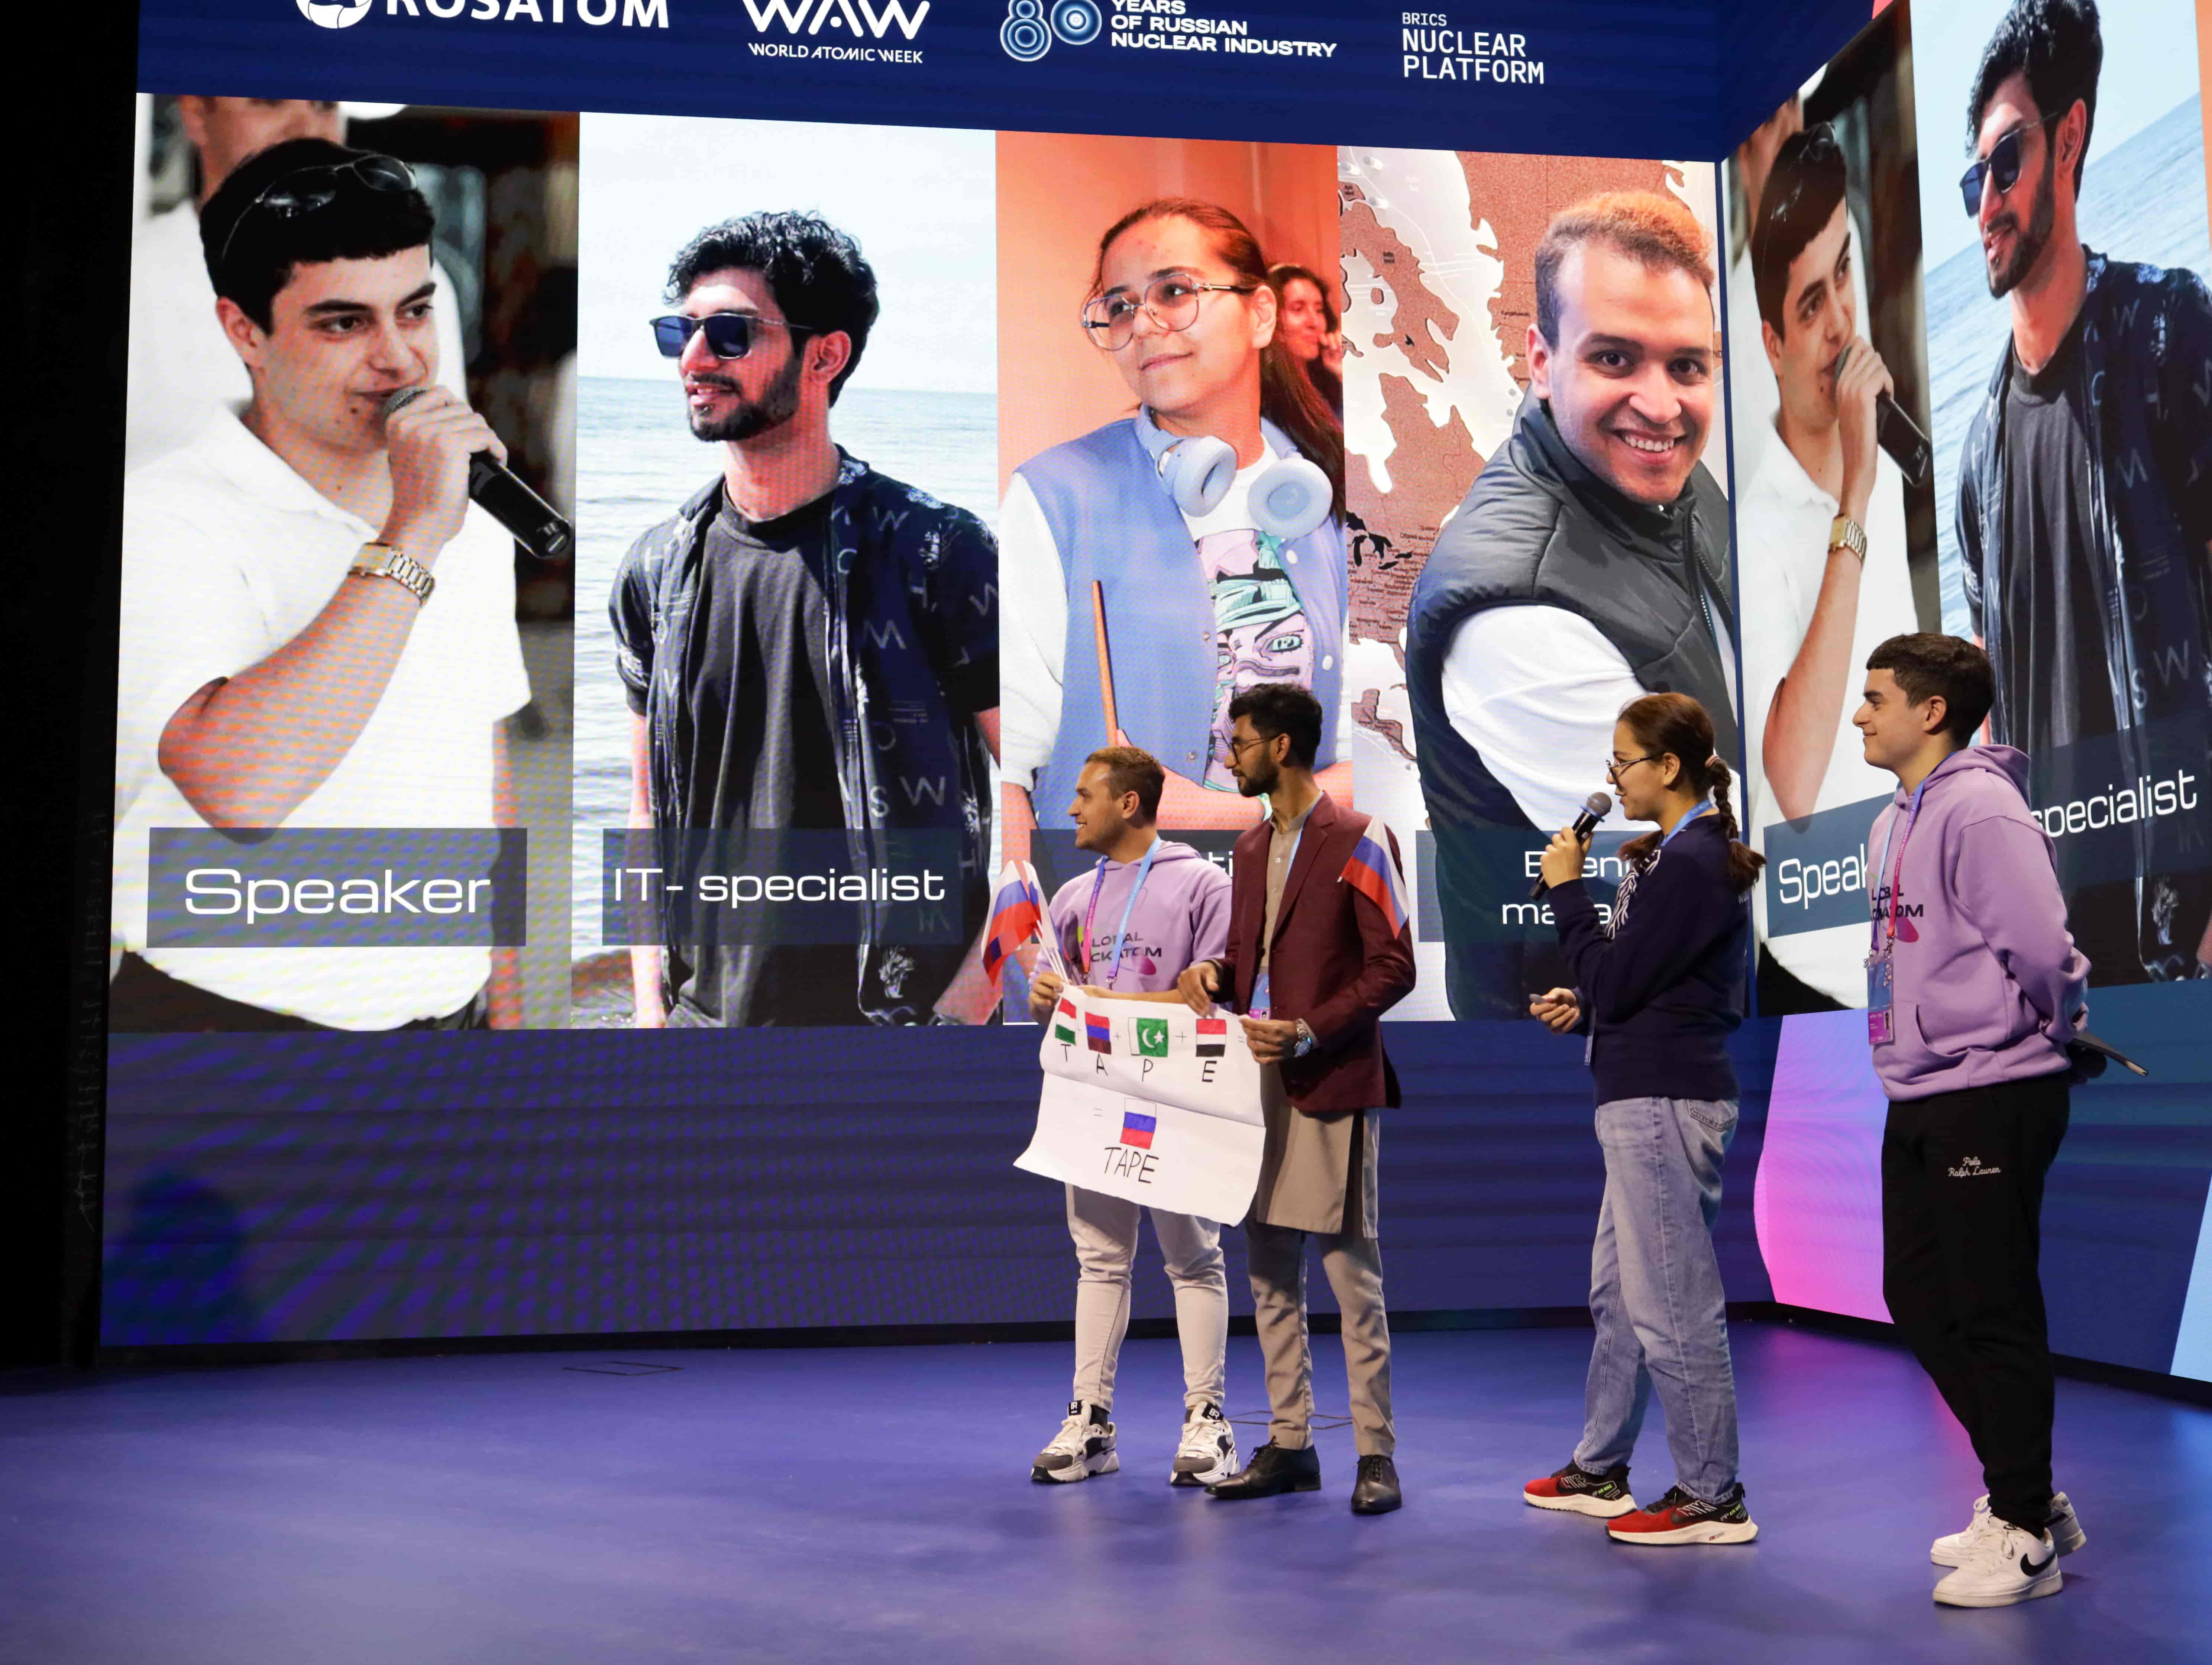
World Atomic Week — Global HackAtom
ROSATOM · Moscow, Russia · 35+ Countries · 1,200+ Participants
Participation Certificate
Represented ITMO University at the Global HackAtom championship, contributing to nuclear-technology innovation solutions. Engaged with industry experts across energy systems and global R&D trends.
06

Media & Press

ITMO News Interview
Featured Interview: A Master's Student's Perspective on Robotics & AI
ITMO.NEWS · Student Feature · Saint Petersburg, Russia
Sat down with ITMO News to share perspectives on the evolving fields of robotics and artificial intelligence, plus practical advice for prospective students from Pakistan considering ITMO.
Read Interview
07

Contact

Let's build something
intelligent together.
Open to PhD research opportunities, robotics/AI engineering roles, and research collaborations. Based in Saint Petersburg, originally from Karachi. I respond within 24 hours.
Send a Message
Have a project or opportunity in mind? Let's connect.
Send Message